PGEA Series Industrial Slim Parallel Electric Gripper
The PGE series is an industrial slim parallel electric gripper independently developed and manufactured by DH Robotics. With precise force control, a compact body, and fast response, it has become a representative product in the field of industrial electric grippers.
DH Robotics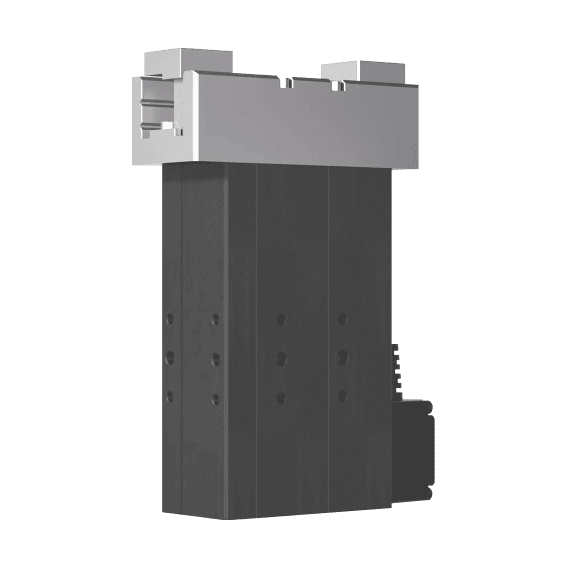
Specifications
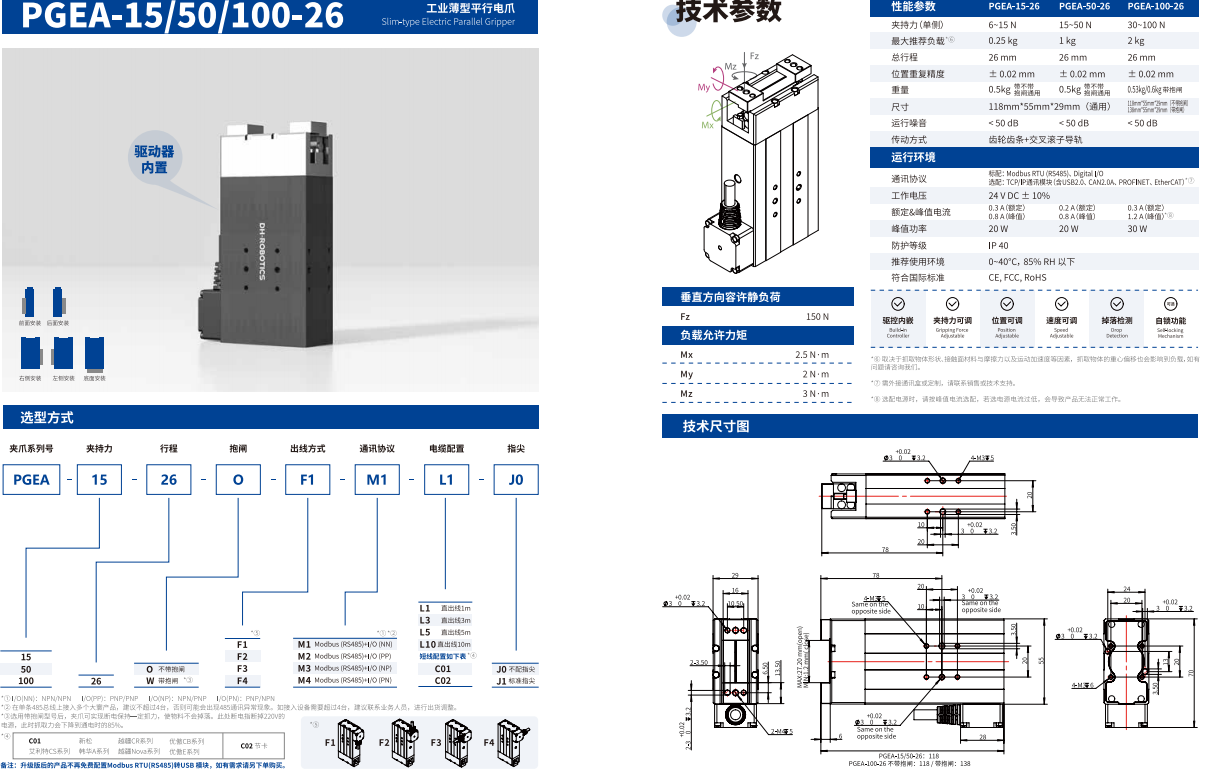
| Parameter | PGEA-15-26 | PGEA-50-26 | PGEA-100-26 | PGEA-15-40 | PGEA-50-40 | PGEA-100-40 |
|---|---|---|---|---|---|---|
| Product image |  |  |  |  |  | |
| Gripping force (per side) | 6-15 N | 15-50 N | 30-100 N | 6-15 N | 15-50 N | 30-100 N |
| Total stroke | 26 mm | 26 mm | 26 mm | 40 mm | 40 mm | 40 mm |
| Max. recommended payload | 0.25 kg | 1 kg | 2 kg | 0.25 kg | 1 kg | 2 kg |
| Position repeatability | ± 0.02 mm | ± 0.02 mm | ± 0.02 mm | ± 0.02 mm | ± 0.02 mm | ± 0.02 mm |
| Weight | 0.5 kg same with or without brake | 0.5 kg same with or without brake | 0.53 kg/0.6 kg with brake | 0.6 kg same with or without brake | 0.6 kg same with or without brake | 0.6 kg same with or without brake |
| Operating noise | < 50 dB | |||||
| Transmission | Rack and pinion + crossed roller guide | |||||
| Communication protocol | Standard: Modbus RTU (RS485), Digital I/O Optional: TCP/IP, USB2.0, CAN2.0A, PROFINET, EtherCAT | |||||
| Operating voltage | 24 V DC ± 10% | |||||
| Rated & peak current | 0.3 A (rated) 0.8 A (peak) | 0.2 A (rated) 0.8 A (peak) | 0.3 A (rated) 1.2 A (peak) | 0.3 A (rated) 0.8 A (peak) | 0.2 A (rated) 0.8 A (peak) | 0.3 A (rated) 1.2 A (peak) |
| Peak power | 20 W | 20 W | 30 W | 20 W | 20 W | 30 W |
| Protection rating | IP40 | |||||
| Recommended operating environment | 0~40 °C, below 85% RH | |||||
| International standards | CE, FCC, RoHS | |||||
Downloads
PGEA Series Industrial Slim Parallel Electric Gripper Product SpecificationDownload
PGEA Series Industrial Slim Parallel Electric Gripper Operation ManualDownload
PGEA Series Industrial Slim Parallel Electric Gripper 2D DimensionsDownload
PGEA Series Industrial Slim Parallel Electric Gripper 3D ModelDownload