FARM200 Truss Tomato Picking Robot Product Specifications
Product specifications
FARM200 Truss Tomato Picking Robot Product Specifications
PDF2026-10-151.23 MB
Download
Product introduction
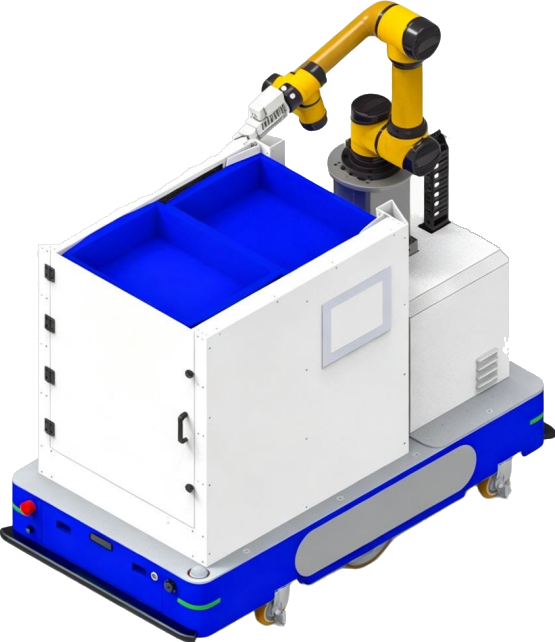
The truss tomato picking robot is developed for modern agricultural greenhouse scenarios. It integrates autonomous mobility, intelligent recognition, and precise picking. The equipment can operate stably on rails or flat ground. By identifying the ripeness and position of truss tomatoes through its vision system, it performs information statistics, intelligent obstacle avoidance, and damage-free harvesting with a collaborative robot arm, realizing full-process automation from inspection to picking.
Features and advantages
- Intelligent recognition with stereo vision: Deep learning determines the position and ripeness of the fruits.
- Precise positioning through visual servoing: Closed-loop control of the multi-joint robot arm.
- Flexible, damage-free picking and basket loading: Integrated cutting-and-clamping end effector.
- Driverless automatic rail switching: Flexible deployment on rails and flat ground.
- Full-area perception and autonomous operation and maintenance: Intelligent obstacle avoidance, charging, and multi-mode travel.