AUBO Fenghe Series FARM200 Agricultural Picking Robot Hardware Manual
1 Introduction
Product application and scope of application
The AUBO Haina series mobile collaborative robot can flexibly control tools such as the collaborative robot, automated guided vehicle (AGV), vision system, and end gripper. The all-in-one control system provides a simple, convenient, safe, reliable, flexibly expandable, and efficient collaborative full-scenario interactive experience. It can flexibly adapt to various working environments, eliminating complicated operations. It achieves object sorting and transportation in a mobile space through hand-eye-foot coordination. It can be used for workpiece grasping, assembly, handling, loading, and unloading, and can also be quickly deployed in automated factories, warehouse sorting, automated supermarkets, and many other scenarios, providing automated and flexible operational support for automated material handling and sorting.
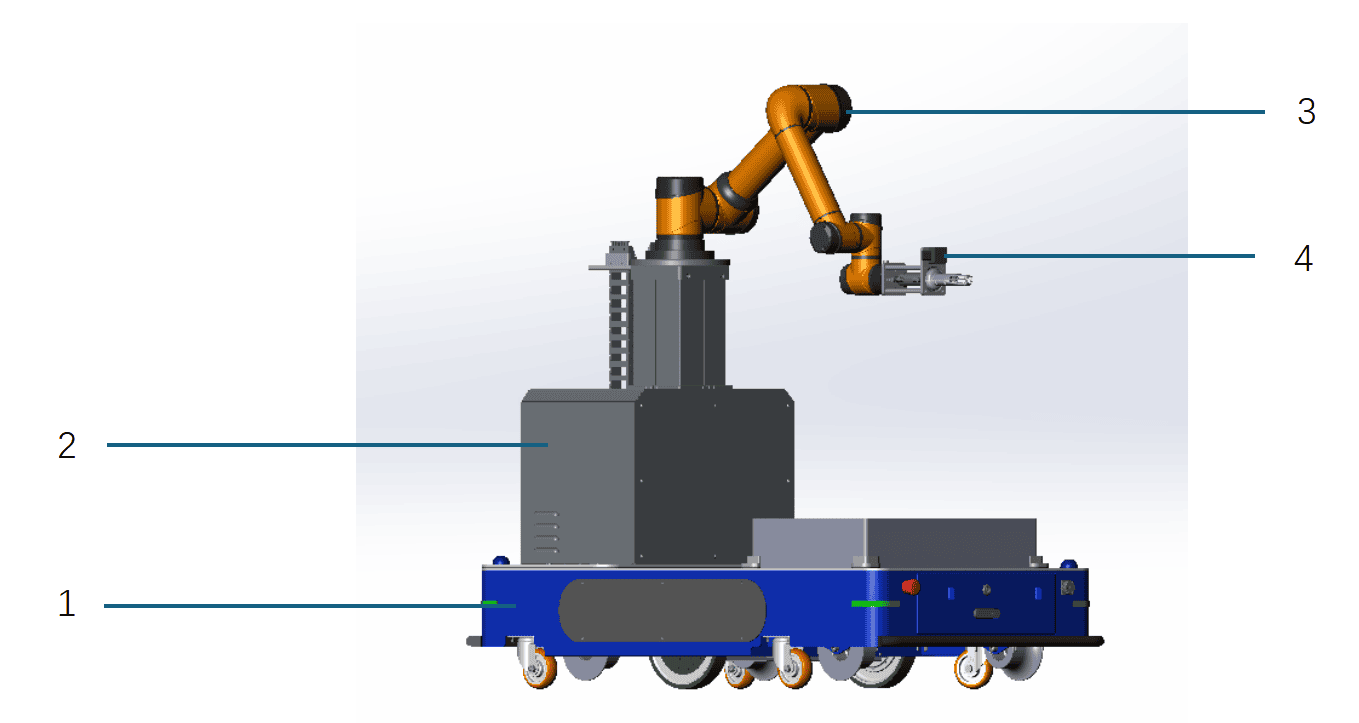
- FARM200
- Second-layer structure (lifting/fixed)
- AUBO collaborative robot
- Gripper with vision (electric/pneumatic)
2 Automated guided vehicle (AGV)
2.1 Basic functions
The automated guided vehicle (AGV) mainly has the following functions:
- Simultaneous localization and mapping (SLAM)
- Station creation and path planning
- Path navigation
- Automatic docking for charging
- Safety emergency stop and safety deceleration
- A variety of function buttons and components
- Mechanical, hardware, and software interfaces for development
2.2 Buttons and components
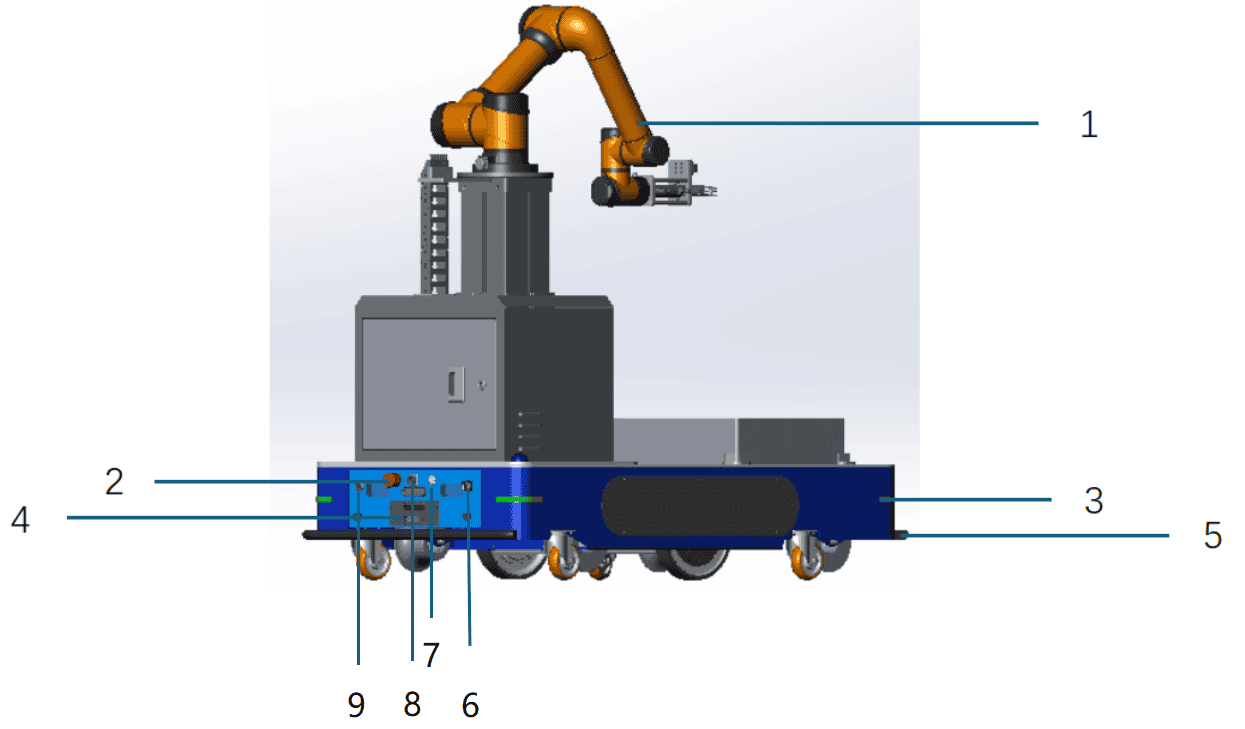
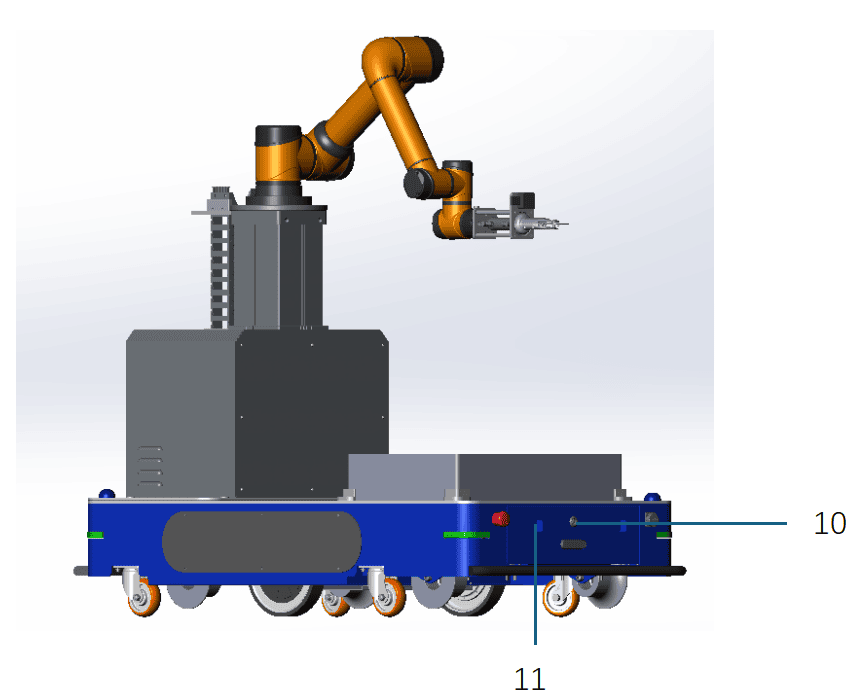
| No. | Button/Component | Description |
|---|---|---|
| 1 | AUBO collaborative robot | AUBO six-axis collaborative robot arm |
| 2 | Emergency Stop button | Press to achieve an emergency stop of the robot. To restore to normal mode, rotate this button in the direction shown on it |
| 3 | Ambient light | Indicates the robot's current status and battery level |
| 4 | Automatic charging port | Port for connecting to the automatic charger |
| 5 | Anti-collision safety edge | Used for AGV collision protection |
| 6 | Brake release switch | Rotate the brake release switch clockwise to push the AGV manually |
| 7 | Power button | Press and hold this button to turn the AGV on or off |
| 8 | Manual charging port | Port for connecting to the manual charger |
| 9 | Compartment door keyhole | Used to open the AGV compartment door |
| 10 | Battery holder keyhole | Used to release or lock the battery holder latch |
| 11 | Battery holder handle | Used for battery replacement |
2.3 Technical parameters
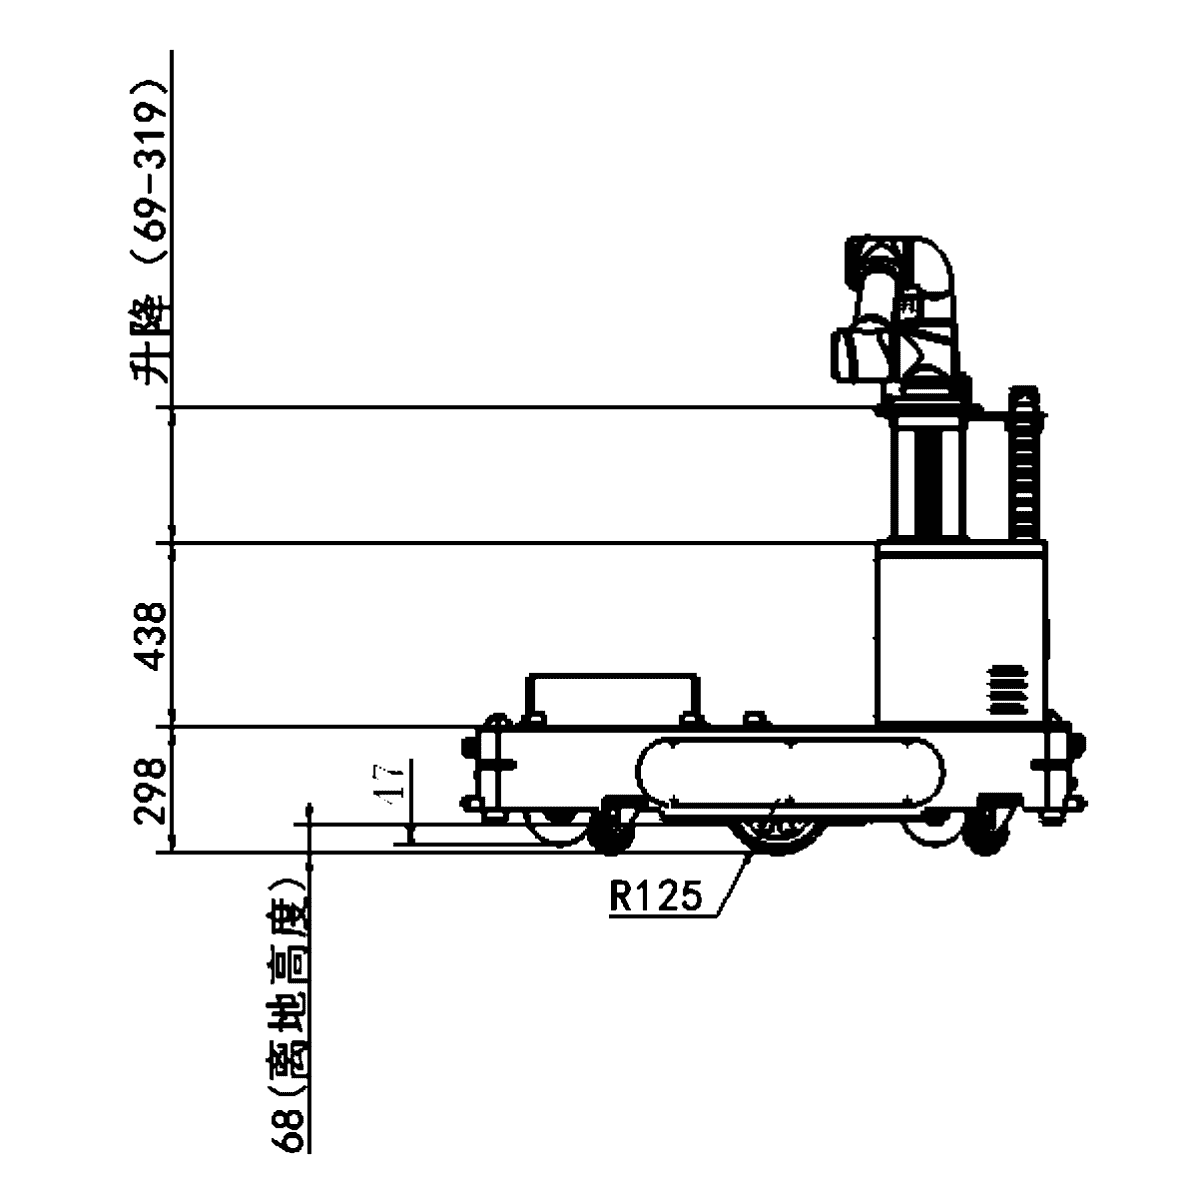
Side view of AGV
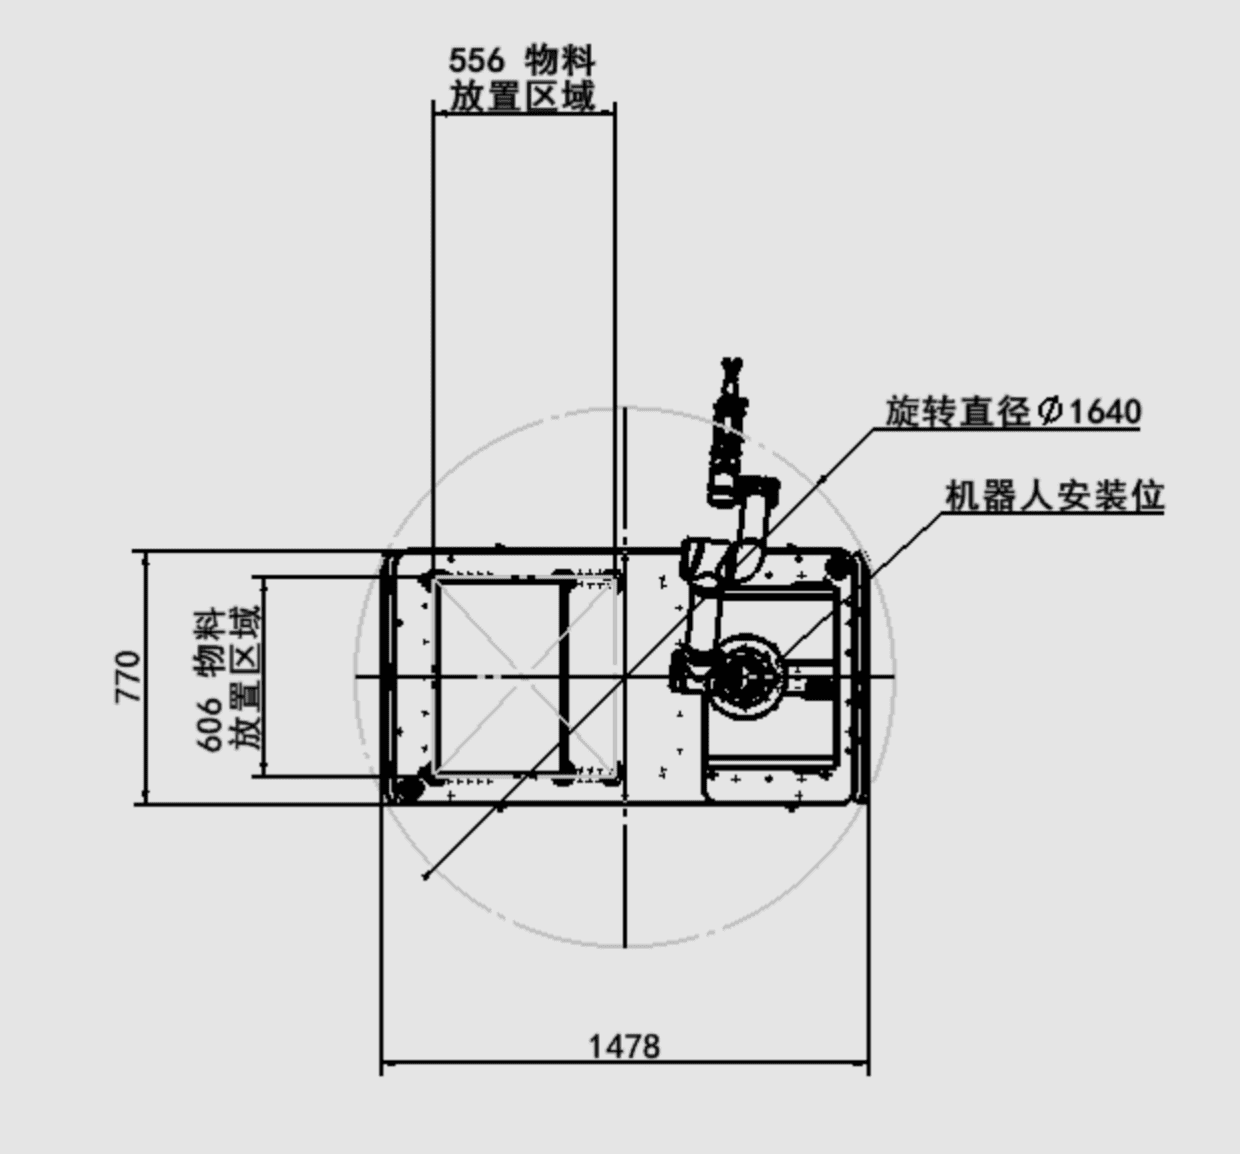
Top view of AGV
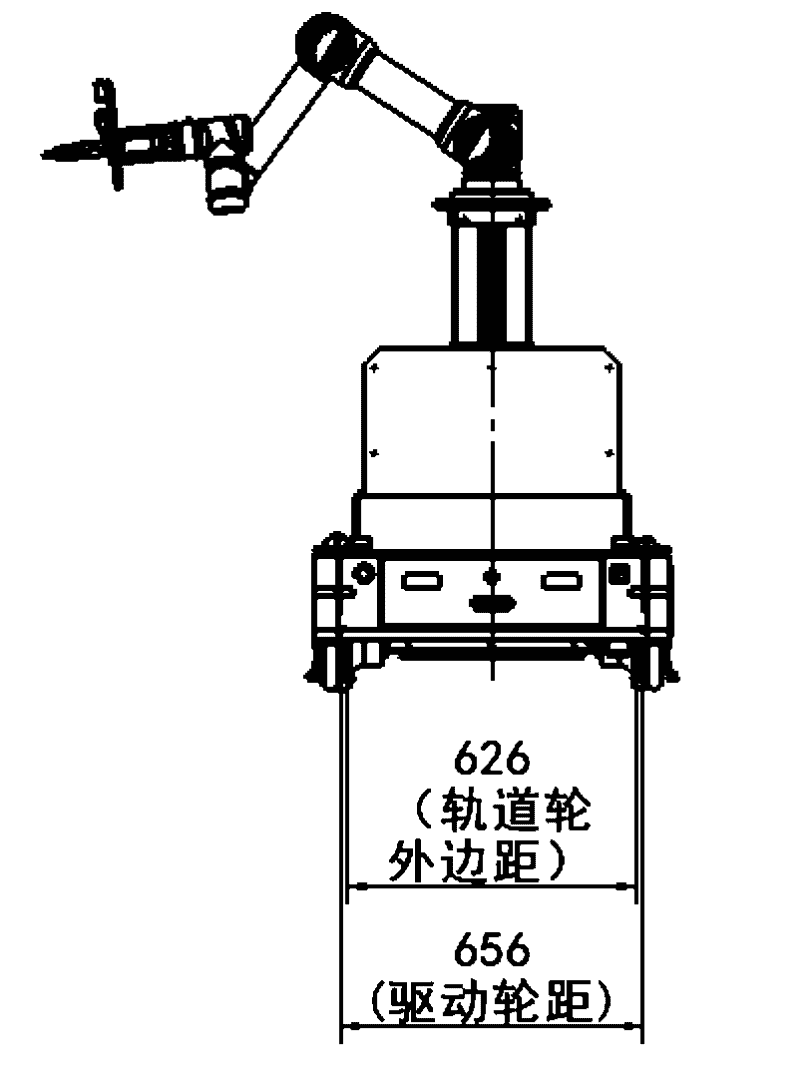
Rear view of AGV
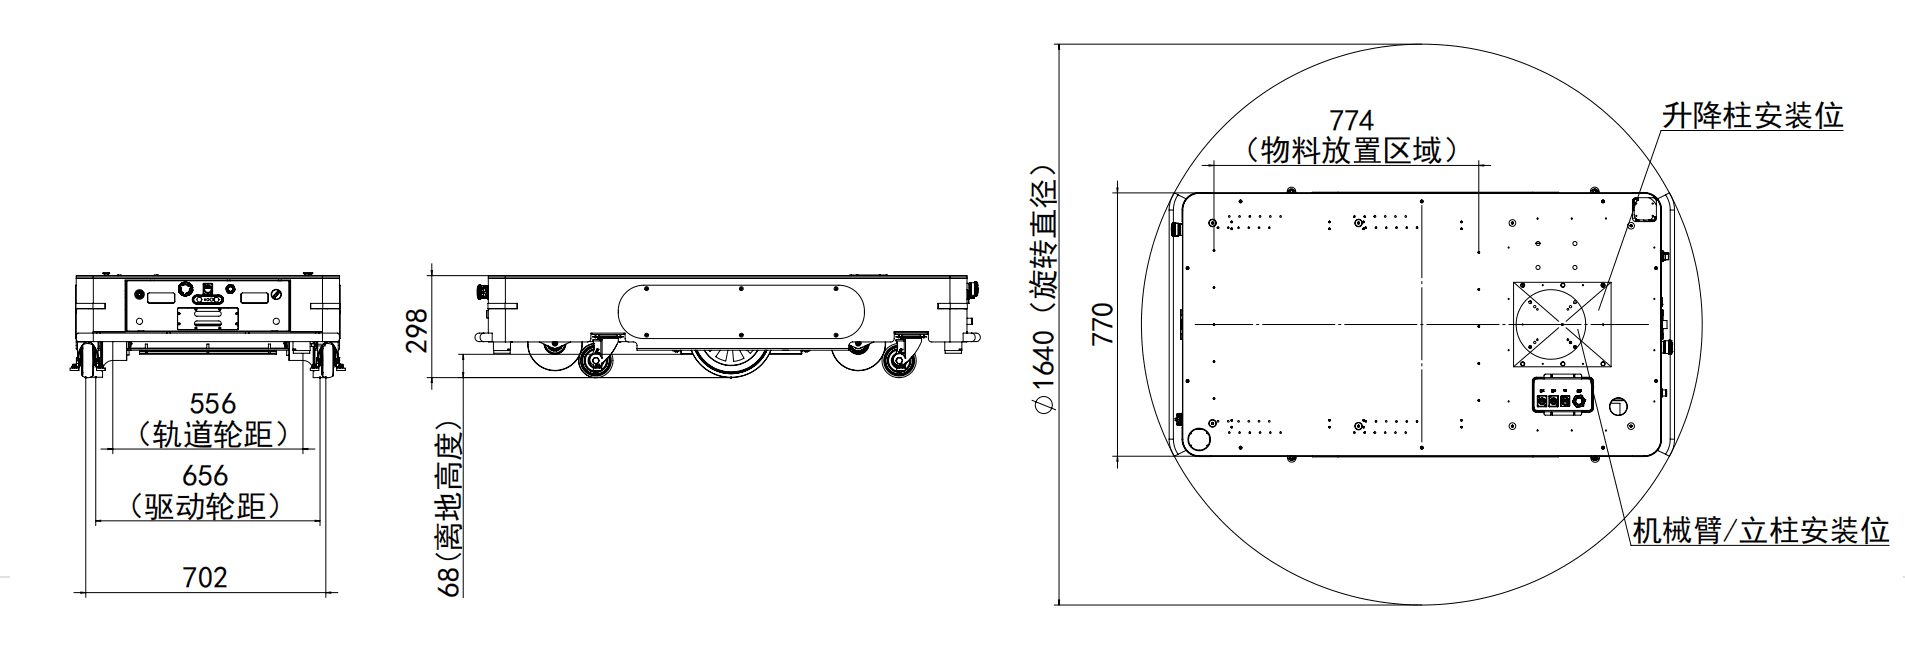
Schematic diagram of the chassis structure
Schematic diagram of the lifting column
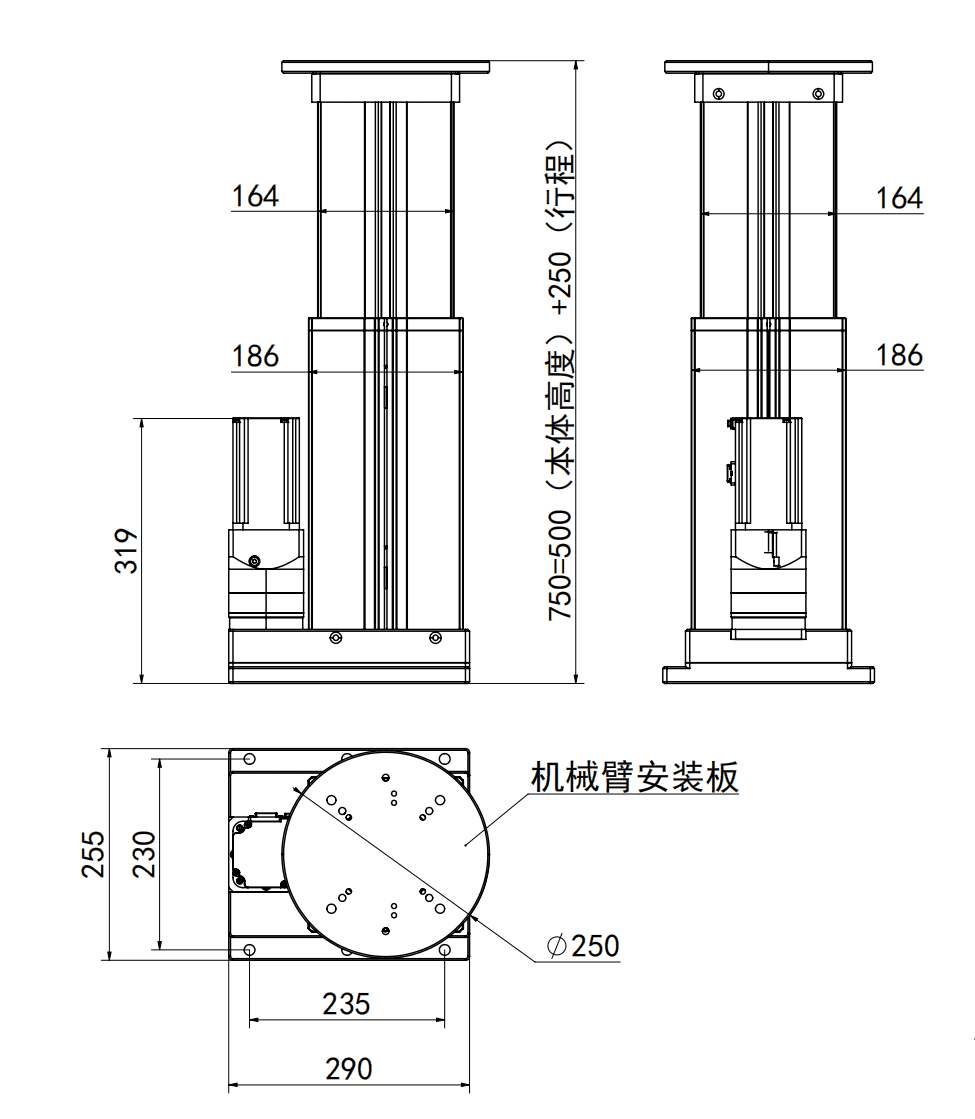
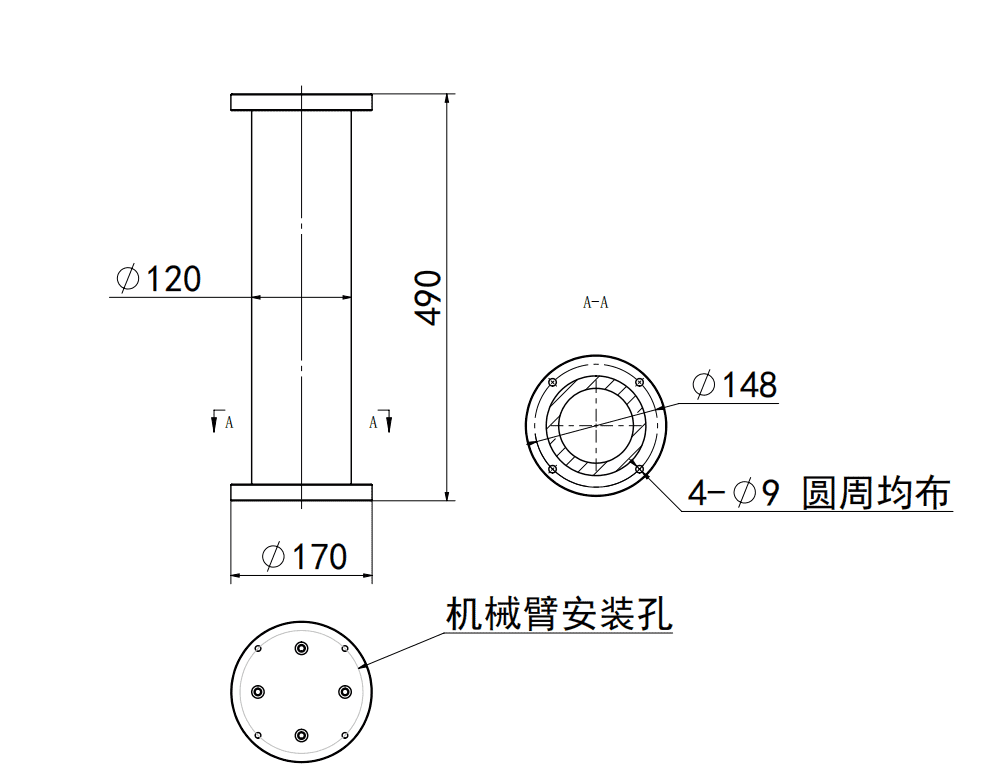
Schematic diagram of the column
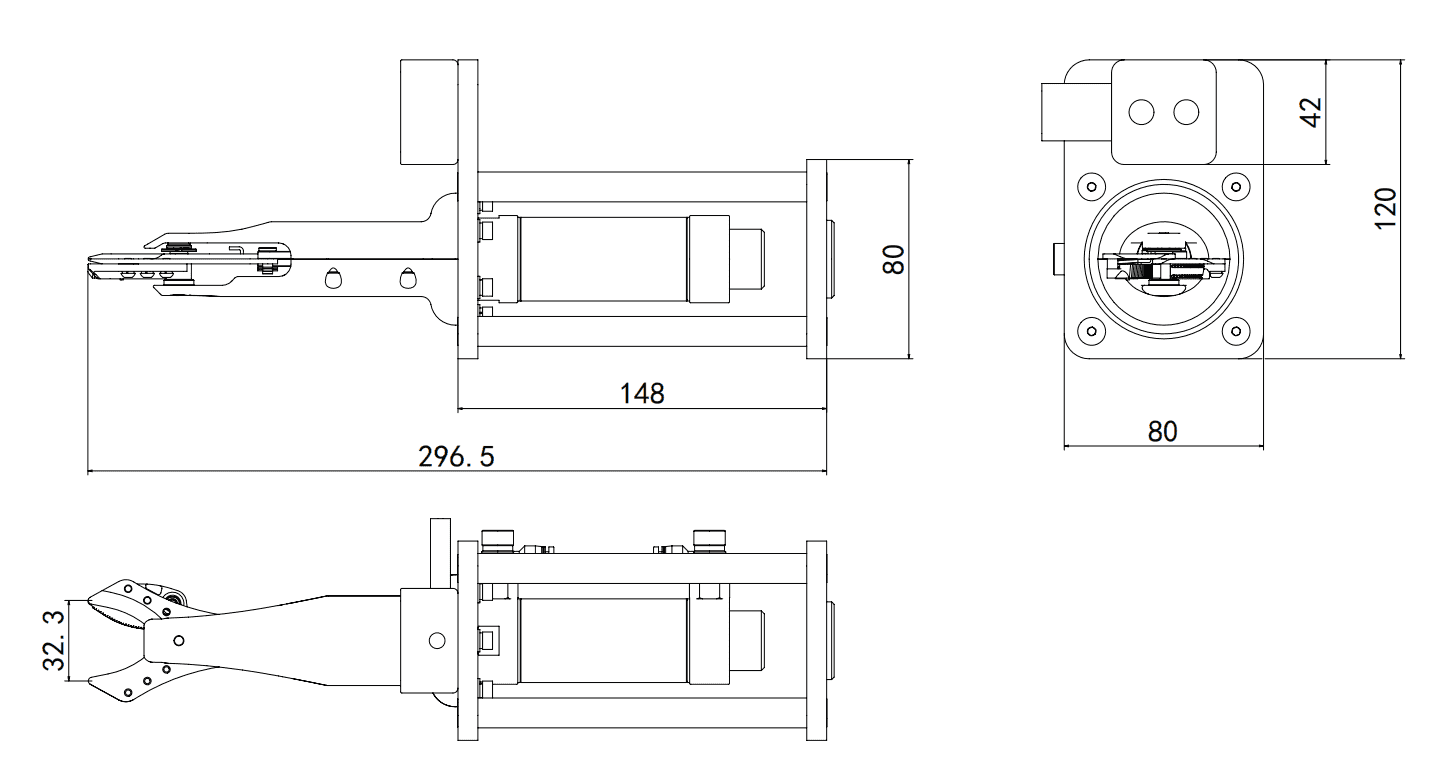
Schematic diagram of the pneumatic scissors
Schematic diagram of the electric scissors
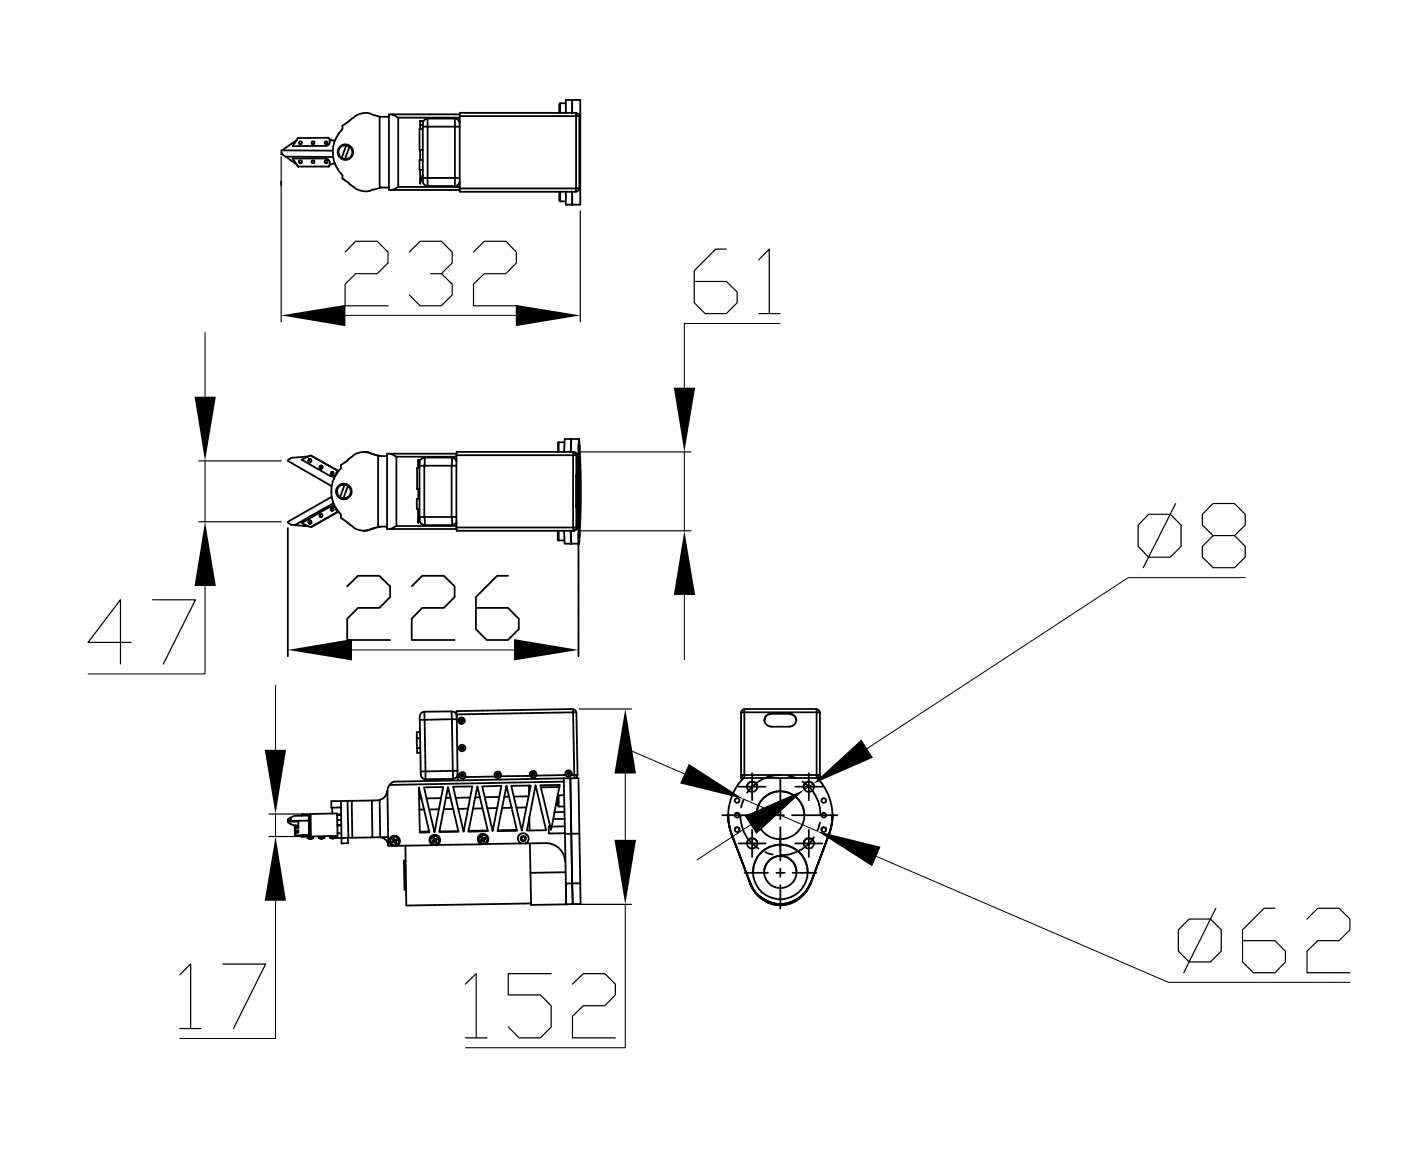
2.4 Parameter description
| Parameter name | Parameter description |
|---|---|
| Product model | FARM200 |
| Dimensions (L*W*H) | 1478*770*298 mm (excluding the second layer and the robot arm height), tolerance ±2 mm |
| Load surface dimensions (L*W) | 606*556 mm, tolerance ±2 mm |
| Dead weight | 280 kg (excluding the robot arm) |
| Maximum payload | 200 kg (including the robot arm and carrier weight) |
| Drive type | Two-wheel differential drive |
| Number of laser sensors | 2 |
| Motion parameters | |
| Maximum speed | 1.5 m/s |
| Operating speed | Forward: 1.0 m/s (configurable), backward: 1.0 m/s (configurable) |
| Turning radius | 0 mm |
| Rotation radius | 820 mm |
| Gradeability | Less than 15° |
| Ground clearance | 68 mm |
| Maximum obstacle clearance height | 50 mm |
| Maximum gap crossing width | Less than 35 mm |
| Station locating accuracy | ±10 mm |
| Battery performance | |
| Battery capacity | 48 V 80 Ah |
| Charger power supply parameter | AC 220 V |
| Battery life | ≥8 h |
| Battery cycle life | 800 cycles (100% DOD), with 80% capacity retention |
| Charging method | Manual charging, manual battery swap, automatic charging |
| Charging time | 3 h (from 15% to 95%) |
| Optional equipment | |
| Robot arm | C series, H series, IS series; 3 kg, 5 kg, 7 kg, 10 kg |
| Vision picking system | Can recognize truss tomatoes, including position and ripeness information, Recognition success rate ≥80%; Ripeness recognition accuracy ≥80% |
| End effector | Pneumatic scissors, electric scissors |
| Automatic lifting column | Body height: 500 mm Stroke: 250 mm Speed: 0-50 mm/s Load: 1000 N Signal type: EtherCAT |
| Fixed column | Height: 490 mm |
| Battery pack | 80 Ah 120 Ah |
| Automatic charging pile | AC 220 V |