AUBO-ES5 Series Six-Axis Collaborative Robot User Manual
1 About This Manual
1.1 Version Information
| Item | Description |
|---|---|
| Manual name | AUBO-ES5 Series Six-Axis Collaborative Robot User Manual |
| Manual version | v0.0.4 |
| Release date | 2026-09-22 |
| Applicable products | AUBO-ES5 |
This user manual is reviewed and revised periodically. Updates will be released with new versions. The content or information in this manual is subject to change without prior notice.
Before installing or using the product, read this manual thoroughly and keep it properly for future reference.
All images in this manual are for illustrative reference only. The actual product shall prevail.
1.2 Copyright and Disclaimer
This manual is proprietary to AUBO (Beijing) Intelligent Technology Co., Ltd. Without the written permission of AUBO (Beijing) Intelligent Technology Co., Ltd., it may not be photocopied, reproduced in whole or in part, or converted into any other format.
AUBO (Beijing) Intelligent Technology Co., Ltd. shall not be liable for any errors or omissions that may appear in this manual, or for incidental or consequential injury or damage arising from the use of this manual and the products described herein.
Copyright © 2015-2026 AUBO. All rights reserved.
1.3 Purpose of This Manual
This manual provides guidance for the installation, commissioning, maintenance, repair, and disassembly of the AUBO-ES5 series six-axis collaborative robot.
This manual does not replace the system integrator's risk assessment, on-site safety design, operating instructions, or applicable laws, regulations, and safety standards of the country or region where the robot system is used.
1.4 Target Audience
This manual is intended for the following qualified personnel:
- Installation personnel
- Maintenance personnel
- Repair personnel, etc.
1.5 Operation Prerequisites
Personnel who read and use this manual must meet the following requirements:
- Have received AUBO training;
- Possess the knowledge required for the installation, repair, and maintenance of mechanical and electronic equipment;
- Have basic safety operation awareness;
- Have read and understood the safety instructions in this manual and related documents.
1.6 Related Documents
When using this manual, it is recommended to also read the following documents:
1.7 Preface
Thank you for purchasing and using the AUBO-ES5 collaborative robot developed by AUBO.
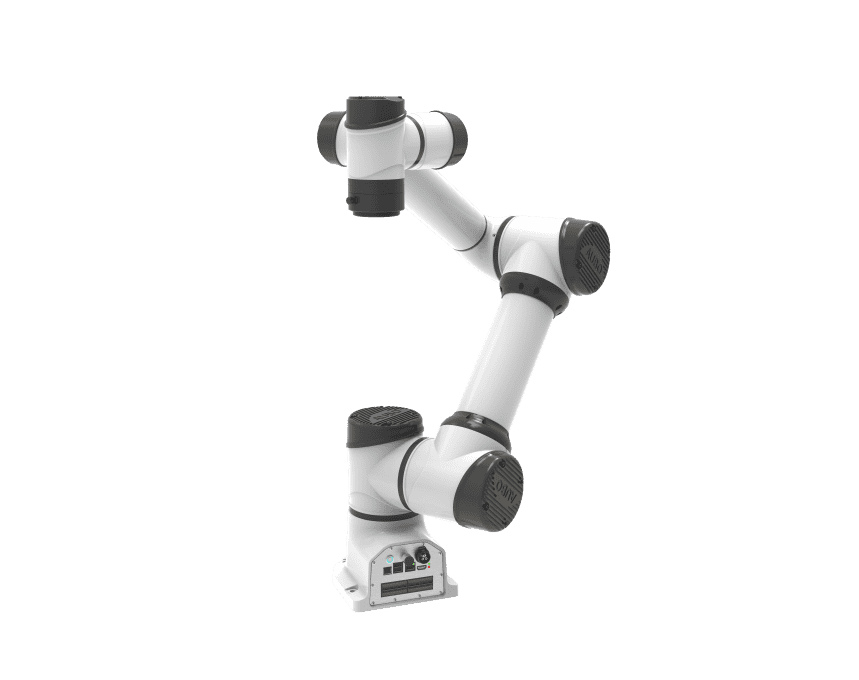
This manual is the user manual for the AUBO-ES5. It is intended to provide guidance for users to use the robot safely and effectively. Be sure to read this manual carefully before use. All images in this manual are for reference only; the actual product shall prevail.
None of the safety-related information contained in this manual shall be regarded as a guarantee by AUBO (Beijing) Intelligent Technology Co., Ltd. Even if all safety instructions are followed, personal injury or equipment damage caused by operators may still occur.
AUBO (Beijing) Intelligent Technology Co., Ltd. is committed to continuously improving product reliability and performance and therefore reserves the right to upgrade products without prior notice. AUBO (Beijing) Intelligent Technology Co., Ltd. strives to ensure the accuracy and reliability of the content of this manual but is not responsible for any errors or omissions therein. The company assumes no liability for personal injury or equipment damage caused by failure to use this equipment correctly in accordance with the manual.
1.8 Intended Use
AUBO ES series robots are generally used for automation transformation equipment in educational scenarios, such as acting as operating or fixing tools and equipment, or processing or transferring parts and products. AUBO ES series robots are only allowed to be used under the specified environmental conditions. For specific information about the operating environment and operating conditions, please refer to the appendix.
AUBO ES series robots have special safety rating characteristics and can perform collaborative operations, that is, they can be used without peripheral safety protection devices, but only in situations where risk assessment shows no hazard, that is, without using any safety protection devices and on-site sensing devices, the intended or accidental contact between workers and the AUBO ES series robot or its end effector or parts will not constitute an unacceptable risk, and the intended or accidental contact with other objects in the workspace (tools, equipment, surfaces, etc.) will not constitute an unacceptable risk.
The robot shall not be used in applications contrary to its intended use. Prohibited uses include but are not limited to the following:
- Use in flammable and explosive hazardous environments;
- Use in devices for moving or transporting people or other animals;
- Use in medical equipment and other devices involving human life;
- Use in devices with significant social and public impact;
- Use in environments subject to vibration such as vehicles and ships;
- Use as climbing tools.
1.9 Packing List
When unpacking, check against the attached packing list to ensure that nothing is missing. If any item is missing, please contact your supplier. The product packing list is as follows (for reference only; the actual product shall prevail if there is any difference).
| Name | Quantity | Remarks |
|---|---|---|
| ES5 robot | 1 | |
| Pluggable terminal block/KF12EKD-2.50mm/16P | 4 | |
| Base mounting screws, M8*25mm | 4 | |
| Wireless antenna | 1 | |
| Control handle | 1 | With 2m harness |
| Switching power supply | 1 | |
| 2m AC power cable | 1 | |
| 3m DC power cable | 1 | |
| Tablet computer | 1 | ARCS wireless teaching software pre-installed |
| Accompanying documents (warranty card, certificate of conformity, etc.) | 1 |
1.10 More Information
For more information about products, services, training, or technical support, please visit https://www.aubo-robotics.cn.
2 Safety
2.1 Safety Instructions
This chapter introduces the basic safety principles to be followed when operating the robot arm or robot system. Integrators, users, and operators must read this chapter carefully and strictly observe the instructions marked with safety warning signs.
Due to the complexity and potential hazards of robot systems, this manual cannot list all possible hazardous scenarios. Users and integrators shall conduct risk assessment based on the actual application, end tools, peripheral equipment, working environment, and personnel activity range, and take appropriate risk reduction measures.
2.2 Safety Warning Signs
This manual uses the following safety warning signs to indicate important safety information. When you see the relevant signs, be sure to read and follow the corresponding instructions.
| Sign | Level | Description |
|---|---|---|
 | DANGER | Indicates a potentially hazardous situation which, if not avoided, could result in death or serious injury. |
 | WARNING | Indicates a potentially hazardous situation which, if not avoided, could result in personal injury or serious equipment damage. |
 | CAUTION | Indicates a potentially hazardous situation which, if not avoided, could result in minor personal injury or equipment damage. Matters marked with this symbol may, depending on the specific circumstances, sometimes have the potential for serious consequences. |
 | NOTICE | Indicates a situation which, if not avoided, could result in personal injury or equipment damage. Matters marked with this symbol may, depending on the specific circumstances, sometimes have the potential for serious consequences. |
2.3 General Safety Specifications
The following basic safety guidelines must always be observed when operating the robot arm and its related equipment. This section lists general safety requirements; safety instructions for specific scenarios are detailed in the relevant chapters of this manual.
Be sure to install the machine and all electrical equipment in accordance with the requirements and specifications in this manual.
Before using the machine for the first time and putting it into production, preliminary testing and inspection of the machine and its protection system are required.
Before starting the machine and system for the first time, it must be checked whether the machine and system are complete, whether operation is safe, and whether any damage is detected. During this inspection, compliance with the national or regional safety production regulations in force must be observed, and all safety functions must be tested.
The user must check and ensure that all safety parameters and user programs are correct and that all safety functions work properly. Personnel qualified to operate the robot are required to check each safety function. The robot may only be started after comprehensive and careful safety testing has been passed and the safety level has been reached.
Professional personnel are required to install and commission the machine in accordance with installation standards.
After the machine is installed and constructed, a comprehensive risk assessment must be carried out again and documented.
Safety parameters shall be set and changed by authorized personnel, and passwords or isolation measures shall be used to prevent unauthorized personnel from changing or setting safety parameters. After safety parameters are modified, the related safety functions need to be analyzed.
In the event of an accident or abnormal operation, the emergency stop switch can be used to stop the robot's motion.
The robot arm has a collision detection function. When the external force applied after the robot is powered on exceeds the normal force range set by the user's safety settings, the robot stops automatically to prevent injury to the robot or operators caused by collision. This function is specially designed by the AUBO-ES5 robot arm for human-machine collaboration safety, but it requires that the robot system operate within the normal operating range and use an AUBO series controller. If the user develops their own controller, the robot will not have the above function. The user shall bear the hazardous consequences arising therefrom.
Connecting different machines may increase hazards or create new hazards. Always carry out a comprehensive risk assessment of the entire installation. When different performance levels for safety and emergency stop are required, always select the highest performance level.
AUBO (Beijing) Intelligent Technology Co., Ltd. assumes no liability for damage to the machine or personal injury caused by improper operation of the machine.
Prohibited items:
| Sign | Description |
|---|---|
| 1. It is strictly prohibited to start the robot arm before safety checks and risk assessment are completed. The following checks must be completed before first startup: - System integrity check (mechanical installation, electrical connection, protective grounding) - Testing of all safety functions - Verification of safety parameter correctness - Review of risk assessment documents 2. It is strictly prohibited to power on the robot arm without connecting the protective grounding wire (PE wire). Improper grounding may result in electric shock, equipment damage, or electromagnetic interference. 3. It is strictly prohibited to use the controller in humid environments or environments with conductive dust, which may result in injury or death. 4. It is strictly prohibited to frequently turn the power supply system on and off manually. The robot arm joint modules are equipped with brakes to maintain the robot pose during power-off. Do not frequently turn the power supply system on and off manually. It is recommended that the interval between power cycles be greater than 10s. 5. When the robot arm is running, it is strictly prohibited to touch the joints and motor surfaces. Do not operate or touch the robot while it is working or immediately after it has stopped. Turn off the power supply and wait for one hour for the robot to cool down. 6. It is strictly prohibited to modify safety parameters or bypass safety functions without authorization. |
Operating specifications:
| Sign | Description |
|---|---|
| 1. Ensure that the robot arm and end tool are securely installed. Improper installation may cause equipment to fall or reduce operating accuracy. 2. Ensure that the robot arm has sufficient workspace, without obstacles, sharp corners, or pinch points. Operators' head and face shall be outside the reachable range of the robot arm. 3. Do not connect safety devices to general I/O interfaces; only dedicated safety interfaces may be used. 4. Correctly configure installation parameters, including installation angle, TCP weight and offset, safety parameters, etc. 5. Do not continue using the robot arm if it is damaged. Stop it immediately and contact AUBO or an authorized service provider. 6. Robot arms with large payloads (≥20 kg) must not be moved manually and must be handled using compliant dedicated lifting equipment. 7. A safety assessment must be carried out after each installation to confirm that all safety functions operate properly. |
| 1. Check the insulation and protective measures before transporting the robot arm, and handle it carefully during transportation to avoid collisions. 2. Do not expose the robot arm to strong magnetic fields for a long time, as strong magnetic fields may cause equipment damage. 3. Do not modify the robot arm without authorization. Any unauthorized modification will void the warranty, and AUBO assumes no liability arising therefrom. |
2.4 Personnel Safety
When operating the robot system, personnel safety shall be given priority. Users and integrators shall at least take the following measures:
- Ensure that all relevant personnel have received training from AUBO official (or an AUBO-authorized distributor) and fully understand the safe and standard operating procedures. Training consultation: support@aubo-robotics.cn.
- During operation, tie up long hair, do not wear loose clothing, and do not wear jewelry. When the robot is stationary, it may be in a standby state and shall be regarded as continuously operating; do not approach it at will.
- In emergency situations such as a person being caught or trapped, the joint can be forced to move by pushing or pulling the robot arm forcefully. Manually moving the robot arm without power drive is limited to emergencies and may damage the robot arm joints.
- Personnel shall not place their head, face, neck, fingers, or other body parts in areas where they may be hit, pinched, or caught.
2.5 Responsibilities and Specifications
The robot arm is a component of a complete robot system and does not itself constitute a complete machine. Therefore, this manual does not cover the complete set of design, installation, and operation solutions for the complete robot, nor does it list all types of risk conditions that may affect the safety of peripheral equipment of the entire integrated system. The installation safety performance of the complete robot equipment depends on the design and construction method of the complete integration solution. The equipment integrator must carry out risk assessment throughout the design and installation of the entire integrated system in accordance with locally applicable laws and regulations, safety specifications, and industry standards.
None of the safety-related information contained in this manual shall be regarded as a guarantee by AUBO (Beijing) Intelligent Technology Co., Ltd. Even if operators strictly follow all safety guidelines in this manual, there is still a potential risk of personal injury or equipment damage.
AUBO (Beijing) Intelligent Technology Co., Ltd. continuously optimizes product performance and reliability and reserves the right to iterate and upgrade products without further notice. We have made every effort to ensure that the content of this manual is accurate and reliable, but we assume no liability for omissions or errors in the document.
2.5.1 Integrator Responsibilities
The integrator bears the following key responsibilities:
- Conduct a comprehensive risk assessment of the complete robot system
- Ensure that the design, installation, and commissioning of the entire system meet safety requirements
- Provide necessary training for users and relevant operators
- Develop complete system operating procedures and emergency plans
- Establish and maintain appropriate safety protection measures
- Eliminate hazards or minimize all hazards to an acceptable level using appropriate methods during final installation
- Inform the end user of the residual risks
- Mark the integrator's information on the robot
- Archive all relevant technical documents and risk assessment reports
2.5.2 Reference Standards
Integrators may refer to the following international standards to implement the risk assessment process:
| Standard No. | Name | Description |
|---|---|---|
| ISO 12100:2010 | Safety of machinery — General principles for design — Risk assessment and risk reduction | Basic framework for risk assessment |
| ISO 10218-2:2025 | Robots and robotic devices — Safety requirements — Part 2: Industrial robot systems and robot applications | Safety requirements for industrial robot integration |
| RIA TR R15.306-2014 | Technical report for industrial robots and robot systems — Safety requirements, task-based risk assessment methodology | Guide to task-based risk assessment |
| ANSI B11.0-2010 | Safety of machinery — General requirements and risk assessment | American machinery safety standard |
For applicable standards and regulatory guidelines, please visit the AUBO official website www.aubo-robotics.cn or consult your local regulatory authority.
2.6 Hazard Identification
Risk assessment shall consider potential hazards during normal use, commissioning, maintenance, cleaning, abnormal recovery, and foreseeable misoperation. When using the collaborative robot arm without peripheral safety protection devices, the following potential hazards may be involved:
- Risk of puncture or cut caused by the use of sharp end effectors or tool connectors.
- Risk of exposure when handling toxic, corrosive, or other hazardous substances.
- Risk of operators' fingers or limbs being pinched by the robot arm joints or base.
- Risk of collision with personnel during the movement of the robot arm.
- Risk of objects falling due to improper fixing of the end tool.
- Hazards caused by impact between the robot payload and solid surfaces. The integrator must measure such hazards and their associated risk levels through risk assessment, and determine and implement corresponding measures to reduce the risk to an acceptable level. Please note that other significant hazards may also exist for specific robot equipment.
Combined with the inherent safety design of AUBO robots as well as the safety specifications and risk assessments developed by integrators and end users, the risks associated with collaborative operation of the robot arm can be reduced to a reasonably practicable level. This document is intended to communicate the residual risks existing before robot installation to integrators and end users. If, after risk assessment, the integrator determines that the corresponding application scenario has hazards that may cause unacceptable risk to operators, the integrator must take appropriate risk reduction measures to eliminate or minimize these hazards until the risk level reaches an acceptable standard. The robot shall not be put into use before the necessary risk reduction measures are completed.
If the robot adopts a non-collaborative deployment solution (such as carrying a hazardous tool), the risk assessment results may require the integrator to additionally install safety equipment (such as safety enabling devices) during program development to ensure the safety of personnel and equipment operation.
2.7 Emergency Handling
2.7.1 Emergency Stop Device
Pressing the emergency stop button will immediately stop all movements of the robot arm. The robot arm body is not equipped with a push-button emergency stop device, but devices such as the control handle are equipped with a push-button emergency stop device. For details, please refer to the user manual of the compatible accessory.
| Sign | Description |
|---|---|
| 1. Emergency stop shall not be used as a regular risk reduction measure and shall be regarded as a secondary protective means. 2. If multiple emergency stop buttons need to be connected, they must be included in the risk assessment of the robot application. 3. If the end tool poses a potential threat, it must be integrated into the system's emergency stop circuit. Failure to comply with this warning may result in death, serious personal injury, or significant property damage. 4. Before releasing the emergency stop, confirm that the hazard has been completely eliminated. |
| Pressing the [Emergency Stop Button] triggers a Category 1 stop. For descriptions of stop categories, please refer to Appendix. |
2.7.2 Emergency Joint Movement
In an emergency, the robot arm joints can be moved in the following way:
- Forced dragging: Push or pull the robot arm joints forcefully to force them to move.
| Sign | Description |
|---|---|
| Forcibly moving the robot arm manually is limited to emergencies and may damage the robot arm joints. |
2.7.3 Excessive Force Safety Protection of the Robot Arm
The robot arm is equipped with an excessive force safety protection function. When the robot arm is powered on and stationary, if an operator or other object accidentally collides with the robot arm and the collision force exceeds the safety threshold, the robot arm will move passively in the direction of the collision force. This function can reduce the injury to personnel, other objects, and the robot arm when an operator or other object collides with the robot arm.
| Sign | Description |
|---|---|
| This function can reduce collision injuries, but a risk assessment is required when it is used for other purposes. |
2.7.4 Collision Protection
The robot arm is equipped with a collision protection function. During the operation of the robot arm, if an operator or other object accidentally collides with the robot arm and the collision force exceeds the safety threshold, the robot arm will enter the Category 2 stop state and simultaneously enter the drag teaching mode. At this time, the robot arm can be dragged to a relatively safe position, and then the robot arm can be made to continue running by operating the teach pendant. This function can reduce the injury to personnel, other objects, and the robot arm when an operator or other object collides with the robot arm, and at the same time save the time of restarting the program and improve work efficiency. The safety threshold of the collision force can be changed by setting the collision level.
3 Handling and Transportation Precautions
When hoisting the robot, the moving parts shall be positioned with appropriate measures so that they do not move unexpectedly during hoisting and transportation and cause hazards. During packaging and transportation, packaging shall be carried out in accordance with packaging standards, and the required marks shall be applied to the outside of the packaging box.
During transportation, the robot must be kept stable and secured in an appropriate position.
The controller shall be lifted using the handle.
When moving the robot from the packaging material to the installation position, hold the robot until all bolts of the robot base are fully tightened.
After fixing, power on the robot and adjust the robot pose to a suitable position using the robot drag teaching function.
Keep the original packaging after transportation. Store the packaging materials in a dry place for future repackaging and moving of the robot.
| Sign | Description |
|---|---|
| 1. Ensure that your back or other body parts are not overly strained when lifting the equipment. 2. All regional and national guidelines shall be observed. AUBO (Beijing) Intelligent Technology Co., Ltd. is not responsible for damage incurred during equipment transportation. 3. Ensure that the installation instructions in the manual are strictly observed when installing the robot. |
4 Maintenance and Repair
Maintenance and repair work must strictly comply with all safety instructions in this manual.
Repair must be carried out by an authorized system integrator or AUBO (Beijing) Intelligent Technology Co., Ltd. When returning parts to AUBO (Beijing) Intelligent Technology Co., Ltd., the provisions of the service manual shall be followed.
It must be ensured that the safety level specified for maintenance and repair work is met, the work safety regulations in force in the country or region are observed, and at the same time all safety functions must be tested for proper operation.
The purpose of maintenance and repair work is to ensure the normal operation of the system or to help restore it to a normal state in the event of a system failure. Repair includes fault diagnosis and actual repair.
The following safety procedures and warnings must be followed when operating the robot arm:
| Sign | Description |
|---|---|
| 1. Remove the power cable from the integrated base to ensure that it is completely de-energized. Necessary precautions shall be taken to prevent others from reconnecting the system energy during repair. After power-off, the system shall still be rechecked to ensure that it is de-energized. 2. Check the grounding connection before restarting the system. 3. Observe ESD (electrostatic discharge) regulations when disassembling the robot arm or the integrated base. 4. Avoid disassembling the power supply system of the integrated base. After the integrated base is turned off, its power supply system can still retain high voltage for several hours. 5. Prevent water or dust from entering the robot arm or the integrated base. 6. Replace faulty parts with new parts of the same part number or corresponding parts approved by AUBO (Beijing) Intelligent Technology Co., Ltd. 7. Immediately reactivate all disabled safety measures after the repair is completed. 8. Record all repair operations in writing and keep them in the technical documents related to the entire robot system. The robot arm has no parts that can be repaired by the end user. If maintenance or repair service is required, please contact your dealer or AUBO (Beijing) Intelligent Technology Co., Ltd. |
5 Disposal
AUBO robots must be disposed of in accordance with applicable national laws and regulations and national standards.
6 Quality Assurance
6.1 Product Warranty
The AUBO-ES5 robot arm enjoys a limited warranty period of 12 months.
If the new equipment and its components have defects caused by poor manufacturing or materials within 12 months after being put into use, AUBO (Beijing) Intelligent Technology Co., Ltd. shall provide the necessary spare parts for replacement or repair the relevant parts.
The ownership of the equipment or components that are replaced or returned to AUBO (Beijing) Intelligent Technology Co., Ltd. belongs to AUBO (Beijing) Intelligent Technology Co., Ltd.
If the product is no longer within the warranty period, AUBO (Beijing) Intelligent Technology Co., Ltd. reserves the right to charge the customer for replacement or repair.
Outside the warranty period, if the equipment shows defects, AUBO (Beijing) Intelligent Technology Co., Ltd. shall not be liable for any damage or loss arising therefrom, such as loss of production or damage to other production equipment.
6.2 Disclaimer
If equipment defects are caused by improper handling or failure to follow the relevant information described in the user manual, the "Product Warranty" shall become void.
Failures caused by the following circumstances are not covered by this warranty:
- Products purchased through channels not approved by AUBO;
- Failure to comply with industrial standards or to install, wire, or connect other control equipment as required by the user manual;
- Use beyond the specifications or standards stated for the product;
- Use of this product for purposes other than those specified;
- Use environment conditions beyond the product's rating;
- Use in a grinding environment or special use environment without product protection;
- Product damage caused by improper transportation;
- Failures, damage, or indirect damage caused by accidents or human factors;
- Failures, damage, or indirect damage caused by modification;
- Installation of non-genuine parts or accessories;
- Damage caused by modification, commissioning, or repair of original parts by third parties other than AUBO (Beijing) Intelligent Technology Co., Ltd. or its designated integrators;
- Failures, damage, or indirect damage caused by natural disasters or other force majeure;
- Failures other than the above circumstances that are not caused by the responsibility of AUBO (Beijing) Intelligent Technology Co., Ltd.
The following circumstances are not covered by the warranty:
- The product traceability number cannot be identified.
- The production date or warranty start date cannot be identified.
- Changes to software or internal data.
- The fault cannot be reproduced or identified by AUBO (Beijing) Intelligent Technology Co., Ltd.
- Use of this product in radioactive equipment, biological test equipment, or applications judged by AUBO (Beijing) Intelligent Technology Co., Ltd. to be hazardous.
- Appearance parts and wear parts.
According to the product warranty agreement, AUBO (Beijing) Intelligent Technology Co., Ltd. only makes warranty commitments for defects and deficiencies in products and parts sold to dealers.
Any other express or implied warranties or liabilities, including but not limited to any implied warranties of merchantability or fitness for a particular purpose, shall not be borne by AUBO (Beijing) Intelligent Technology Co., Ltd. In addition, AUBO (Beijing) Intelligent Technology Co., Ltd. shall not be liable for any form of indirect damage or consequences arising from the relevant products.
6.3 List of Wear Parts
| No. | List of wear parts |
|---|---|
| 1 | Nameplate |
| 2 | Rubber ring |
| 3 | Decorative ring |
| 4 | End IO protective cap |
| 5 | Robot arm base mounting screws |
| 6 | Robot arm base aviation connector cover |
7 Robot System Hardware Composition
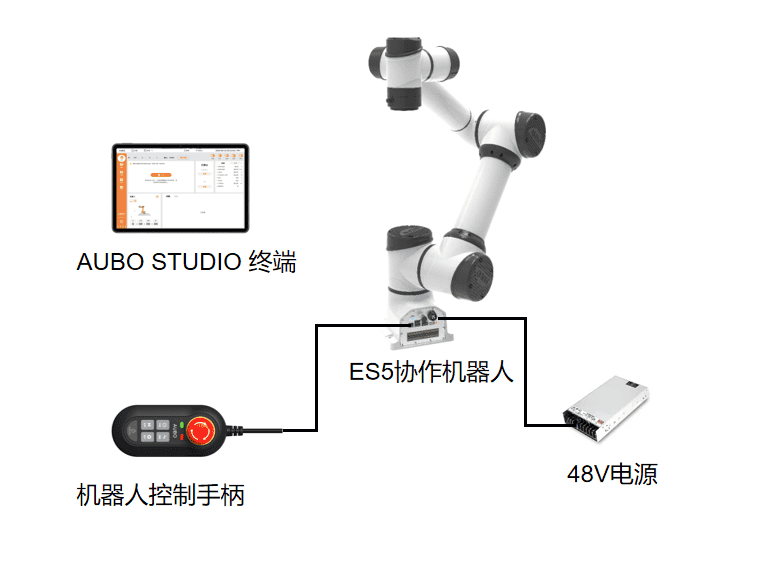
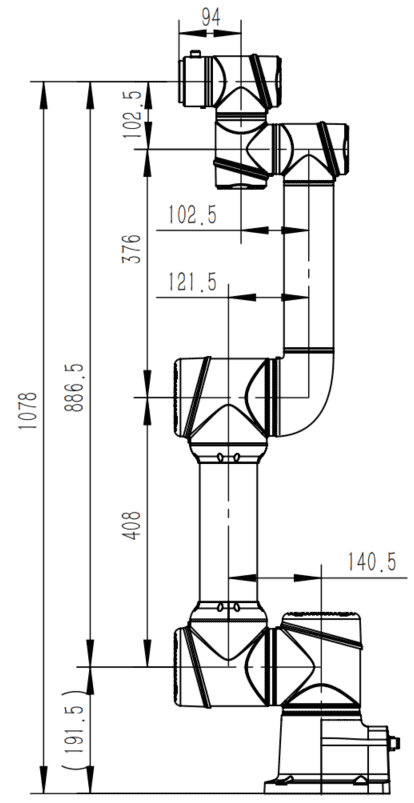
As shown in Figure 7-1, the AUBO-ES5 robot system mainly consists of the robot, the control handle, and the terminal. The robot imitates a human arm and has 6 rotational joints in total, each joint representing one degree of freedom, as shown in Figure 7-2. The base is used to connect the robot body and the base unit, and the tool end is used to connect the robot and the tool. Through the robot control software, users can control the rotation of each joint so that the robot end tool moves to different poses. The tool end has 4 digital input interfaces, 4 digital output interfaces, and 2 analog input interfaces. 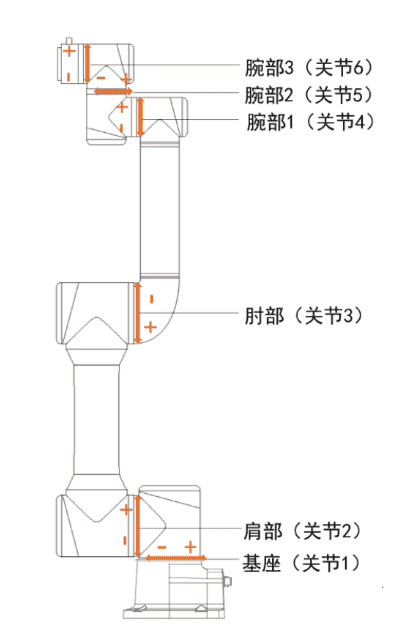
The controller of the AUBO ES series robot is integrated into the integrated base. The control handle is used for safety protection and quick operation. In addition, the robot system also includes an operating terminal (Android tablet), which is used to install the robot teaching software, as shown in Figure 7-3 below. 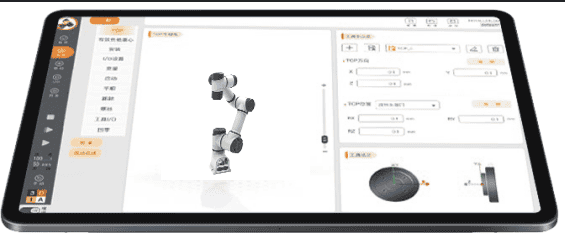
8.2 Robot Motion Range
The motion range of the AUBO-ES5, excluding the cylindrical space directly above and directly below the base, is a sphere with a radius of 886.5mm. When selecting the robot installation position, be sure to consider the cylindrical space directly above and directly below the robot, and avoid moving the tool toward the cylindrical space as much as possible. In addition, in actual applications, the rotation angle ranges of joints 1-6 are respectively: ±360°, ±360°, ±162°, ±360°, ±360°, ±360°. 
The integrated base has both hardware protection and software protection to ensure safety during use to the greatest extent. The integrated base is internally designed with monitoring and protection circuit units, and at the same time, optocouplers are used to completely isolate the high-voltage part from the low-voltage part to protect the control unit. In addition, an emergency stop switch can be externally connected to the integrated base, so that users can cut off the robot power supply in the shortest time to protect the safety of personnel and equipment. 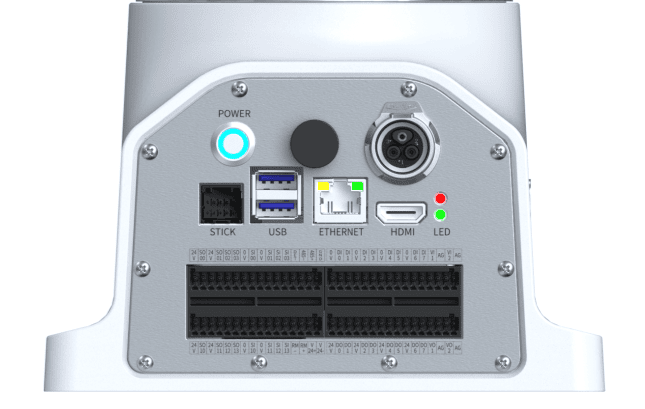
9.2 Important Safety Instructions
| Sign | Description |
|---|---|
| Do not directly touch the screws and other metal components inside the integrated base with your hands, and never remove wiring while it is energized. |
| Precautions before use: 1. Check whether the power cable of the integrated base is properly connected. 2. Check that the integrated base is firmly supported and does not shake. There is a hazardous 48V DC voltage inside the enclosure. Non-professionals shall not open the panel while it is energized. |
| The software in this robot system only supports the upgrade and use of the default software. Installing other software such as the ROS system is prohibited. If software installation is required, users are advised to install it on another platform. |
9.3 Introduction to the Integrated Base Panel
The structure of the integrated base panel is shown in the figure below: 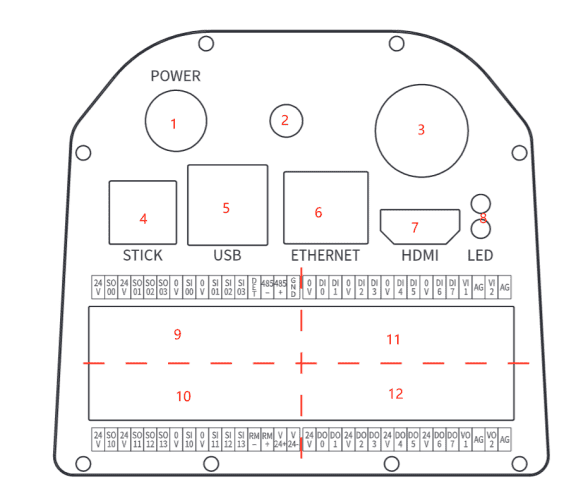
| No. | Name | Function |
|---|---|---|
| 1 | Power on/off button | Used to power on and power off the base. |
| 2 | WIFI antenna | Used to connect to the network and for the connection between its own AP and the tablet. |
| 3 | Power input interface | Connects to an external power supply to power the base. |
| 4 | Control handle interface | Connects to the base handle. |
| 5 | USB interface | Can be used to connect devices and export project files, etc. |
| 6 | ETHERNET interface | Ethernet interface, which can be used for remote access and control. |
| 7 | HDMI interface | Not yet available; can be used for user customization. |
| 8 | Indicator light | Green is the power indicator light, indicating the robot power on/off status: Off: the robot is powered off; Blinking: the robot is powered on and the robot arm is not powered; Steady on: the robot is powered on and the robot arm is powered. Yellow is the connection indicator light, indicating the connection status of the teach pendant software: Blinking: the robot is powered on and the teach pendant software is not connected; Steady on: the robot is powered on and the teach pendant software is connected. |
| 9 | Safety I/O interface | Custom safety I/O interfaces All safety I/O have dual-circuit safety channels (redundant design), which ensures that safety functions are not lost in the event of a single fault. |
| 10 | General I/O interface | 8 general digital input interfaces, 8 general digital output interfaces, 2 analog voltage input interfaces, 2 analog voltage output interfaces, |
| Sign | Description |
|---|---|
| It is prohibited to plug or unplug USB devices while the robot arm is running. |
10 Electrical Interfaces
10.1 Introduction
This chapter describes all electrical interfaces of the integrated base and the robot body. The electrical interfaces are distributed on the integrated base panel and at the wrist of the robot body. Examples are provided for most types of I/O. I/O refers to the digital and analog control signals entering and leaving the electrical interfaces.
10.2 Electrical Warnings and Cautions
The following warnings and cautions must be observed when designing and installing robot applications. These warnings and cautions must also be observed when performing maintenance work.
| Sign | Description |
|---|---|
| 1. Never connect safety signals to non-safety PLCs with an inappropriate safety level. Failure to comply with this warning may result in serious injury or even death due to the failure of a safety stop function. 2. The integrated base must be de-energized when wiring the electrical interfaces of the integrated base. 3. All safety signals have dual-circuit safety channels (redundant design). Keeping the two channels independent ensures that safety functions are not lost in the event of a single fault. |
| 1. Ensure that all equipment that must be kept away from water is kept dry. If water enters the product, cut off the power supply and contact your supplier. 2. Use only the original cables of this robot. Do not use the robot in applications where those cables need to be bent. If longer cables or flexible cables are required, contact your supplier. 3. All GND connectors mentioned in this document are only suitable for power supply and signal transmission. For protective grounding (PE), use the screw connector marked with the grounding symbol in the integrated base. The grounding connector shall have a current rating of at least the highest current in the system. 4. Be careful when installing interface cables to the robot's I/O. |
| 1. This robot has passed the tests specified in the international IEC standards for electromagnetic compatibility (EMC). Interference signals higher than the levels specified in the IEC standards will cause abnormal behavior of the robot. Extremely high signal levels or excessive exposure will cause permanent damage to the robot. EMC problems usually occur during welding and are usually indicated by error messages in the log. AUBO (Beijing) Intelligent Technology Co., Ltd. is not responsible for any loss caused by EMC problems. 2. The length of the I/O cables used to connect the integrated base to other machinery and plant equipment shall not exceed 30 meters, unless extension testing shows that it is feasible. |
10.3 Integrated Base Power Supply I/O Interface
The integrated base has a built-in DC power supply with a voltage of 24V and a maximum current output of 2A, which supports power supply for low-power devices (if high-power devices are used, please use an additional power supply for external power). The power supply wiring is shown in Figure 10-1: 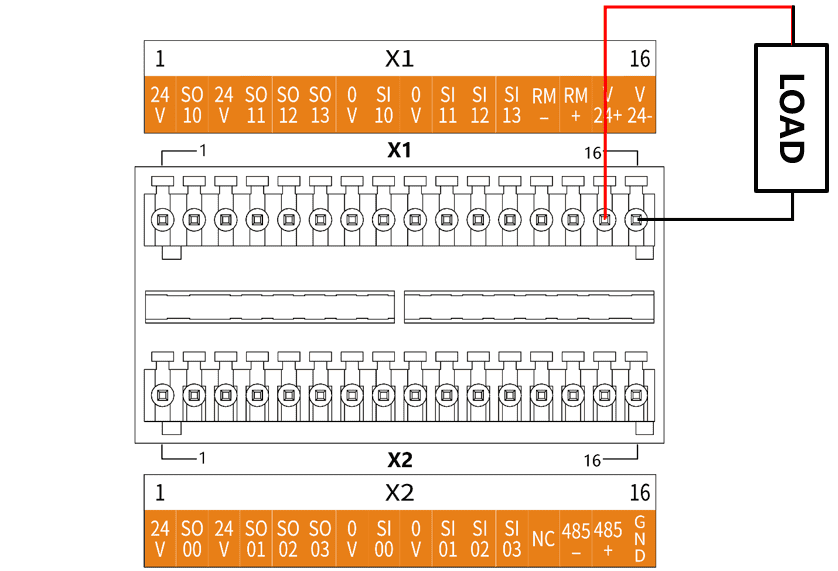
10.4 Safety I/O Interfaces
10.4.1 Introduction
All safety I/O have dual-circuit safety channels (redundant design), which ensures that safety functions are not lost in the event of a single fault. During use, safety devices and equipment must be installed in accordance with the safety instructions and may only be used after a comprehensive risk assessment. The safety I/O are located on the X1 and X2 terminal blocks of the integrated interface on the integrated base panel and must be kept as two branches.
10.4.2 Safety Tips
| Sign | Description |
|---|---|
| 1. Do not connect safety signals to non-safety PLCs with an inappropriate safety level. 2. Be sure to separate safety interface signals from ordinary I/O interface signals. 3. Before using the robot, be sure to check the safety functions; the safety functions must be tested periodically. |
10.4.3 Safety I/O Function Definition
| Input/Output | I/O Name | Function Definition | |
|---|---|---|---|
| Input | SI00 | SI10 | User-defined |
| SI01 | SI11 | User-defined | |
| SI02 | SI12 | User-defined | |
| SI03 | SI13 | User-defined | |
| Output | SO00 | SO10 | User-defined |
| SO01 | SO11 | User-defined | |
| SO02 | SO12 | User-defined | |
| SO03 | SO13 | User-defined |
10.4.4 External Emergency Stop Input
In addition to the emergency stop button on the control handle, ES series robots also support the use of one or more additional emergency stop buttons. Users can connect the emergency stop button by referring to the example in Figure 10-2. Before using this function, users need to configure the function of the corresponding SI interface as "Emergency Stop" in the teaching software. 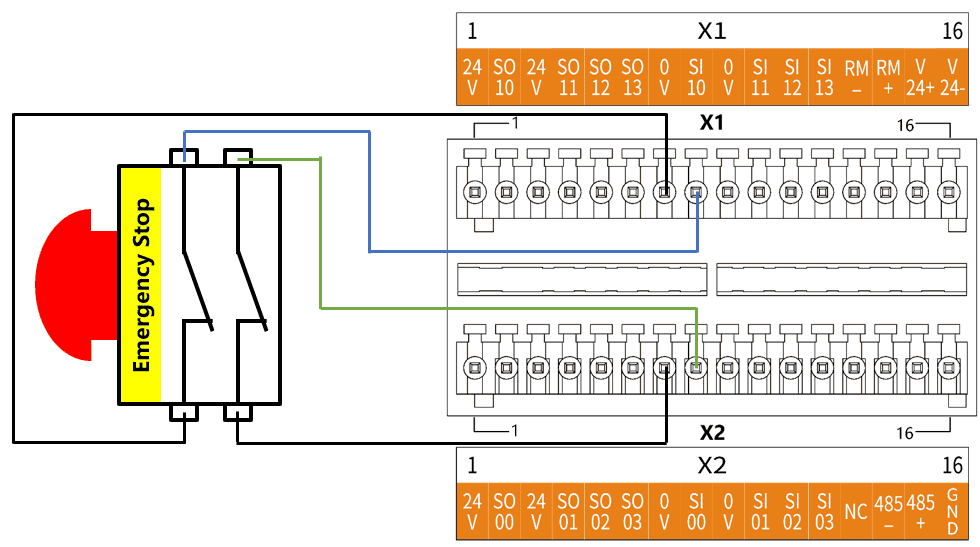
10.4.5 System Emergency Stop Output (Normally Open)
Through this interface, users can output an emergency stop signal to the outside when the robot enters the emergency stop state. Users can connect an external alarm lamp to the system emergency stop output interface by referring to the example figure below. In this configuration, when the robot enters the emergency stop state, the system emergency stop signal is output to the outside, and the external alarm lamp lights up. Before using this function, users need to configure the function of the corresponding SO interface as "High During Internal Emergency Stop/System Emergency Stop" in the teaching software. 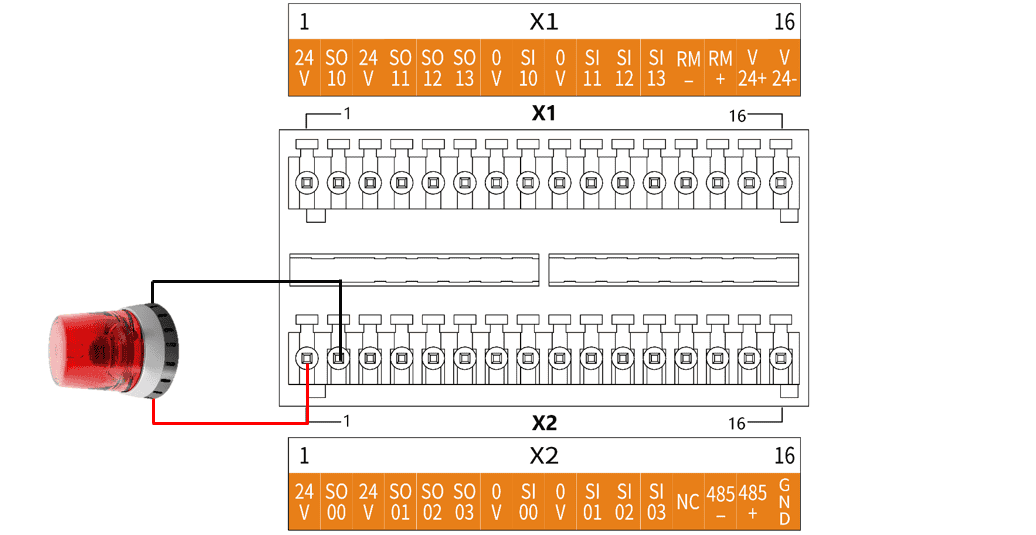
| Sign | Description |
|---|---|
| This function has a wide range of uses; whenever it is used, users need to carry out a complete risk assessment. |
10.4.6 Robot Motion Output
Through this interface, users can output a robot motion signal to the outside when the robot arm is moving normally. Users can connect an external indicator lamp to the robot motion output interface by referring to Figure 10-4. Before using this function, users need to configure the function of the corresponding SO interface as "Robot Moving/Robot In Motion" in the teaching software. 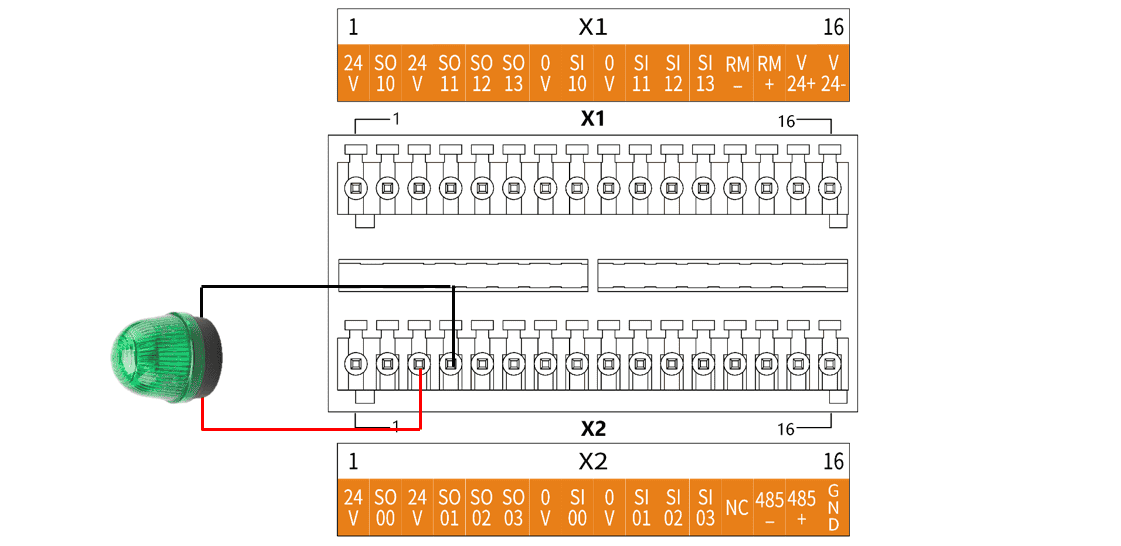
| Sign | Description |
|---|---|
| This function has a wide range of uses; whenever it is used, users need to carry out a complete risk assessment. |
10.4.7 Remote Power On/Off Control
The remote power on/off control I/O interface is shown in the figure below. The remote power on/off interface can be used to control the startup or shutdown of the robot. 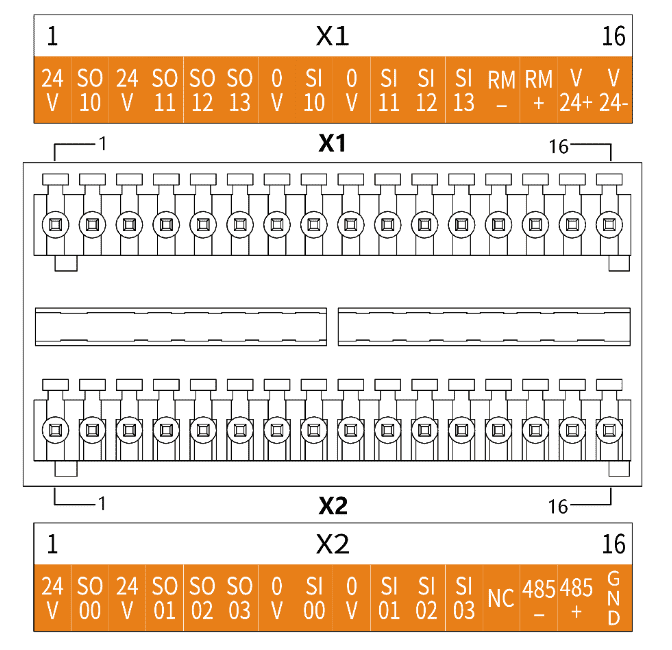
The remote power on/off function of the robot requires the user to provide an external DC24V power supply separately (the robot's built-in DC24V power supply can also be used). Connect the positive and negative poles of the power supply to the RM+ and RM- interfaces respectively. The following is the wiring diagram for remote power on/off. 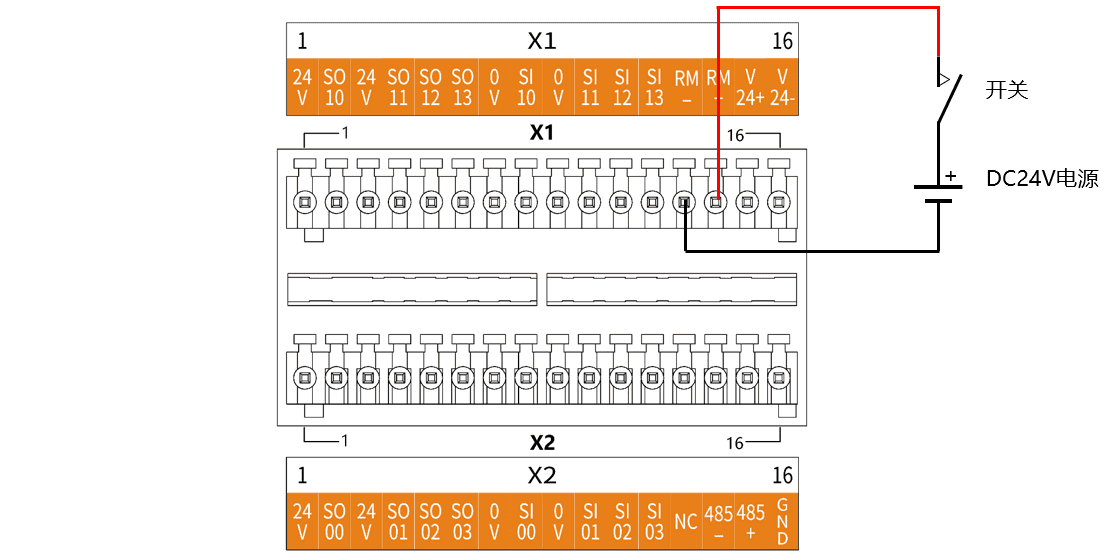
When the robot is powered off, a short press of the switch for more than 100ms powers on the robot; when the robot is powered on, a short press of the switch for more than 100ms powers off the robot.
10.4.8 RS485 Interface
The RS485 interface is shown in the figure below and can be used for Modbus RTU communication.
| Sign | Description |
|---|---|
| When connecting external devices, all external devices must share a common ground with the integrated base. |
10.5.1 General Digital I/O Interfaces
The general digital input terminals (hereinafter referred to as "DI terminals") work in NPN mode, that is, when the DI terminal is connected to ground, the action is triggered; when the DI terminal is disconnected from ground, the action is not triggered. The DI terminal can read the action signals of switch buttons, sensors, PLCs, or other AUBO robots.
The general digital output terminals (hereinafter referred to as "DO terminals") all work in NPN form. The working process of the DO terminal is shown in Figure 10-8: when logic "1" is given, the DO terminal is connected to GND; when logic "0" is given, the DO terminal is disconnected from GND. 
The DO terminal can be directly connected to a load, or communicate with a PLC or other robots.
Users can control the above digital IOs through the teaching software.
| Input | DI00 | DI01 | DI02 | DI03 | DI04 | DI05 | DI06 | DI07 |
|---|---|---|---|---|---|---|---|---|
| Output | DO00 | DO01 | DO02 | DO03 | DO04 | DO05 | DO06 | DO07 |
| DI/DO | Parameter | Specification |
|---|---|---|
| DI | Input signal form | Sink input Voltage-free contact input NPN open collector transistor |
| Input mode | Input signal current | |
| Electrical specification | 5mA/DC24V | |
| DO | Output form | Transistor (sink type) |
| Electrical specification | 300mA/DC24V |
| Parameter | Minimum | Maximum |
|---|---|---|
| Input voltage of a single DI terminal | 0V | 24V |
Examples
Some commonly used wiring examples are listed below.
1. Connecting a button switch to a DI terminal
As shown in the figure below, the DI terminal can be connected to ground (GND) through a normally open button. When the button is pressed, the DI terminal is connected to GND and the action is triggered. When the button is not pressed, the DI terminal is disconnected from GND and the action is not triggered. This is the simplest wiring example. 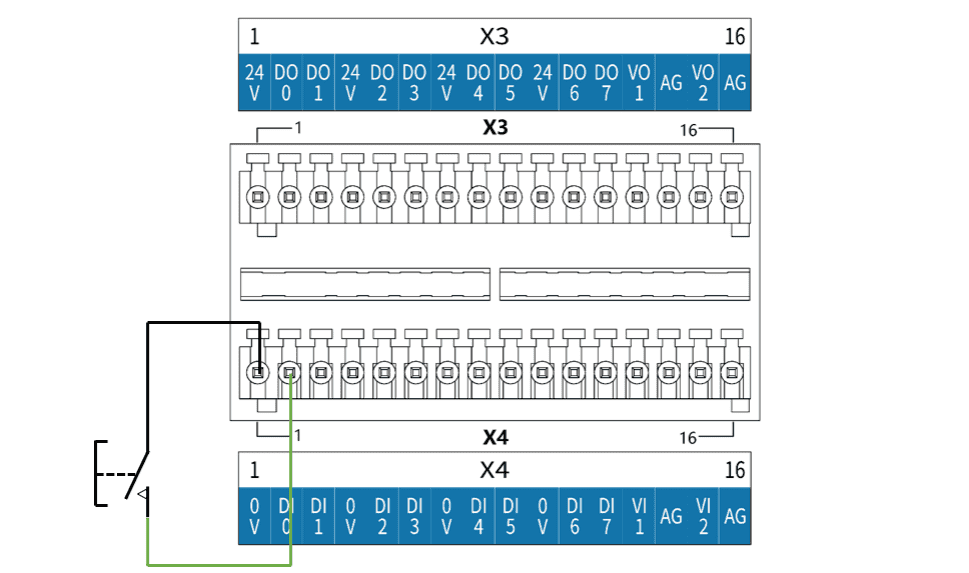
2. Connecting a two-terminal sensor to a DI terminal
As shown in the figure below, a sensor is connected between the DI terminal and GND. If the voltage difference between the OUT terminal and the GND terminal is very small when the sensor is working, the action can also be triggered; when the sensor is not working, the circuit is disconnected and the action is not triggered. 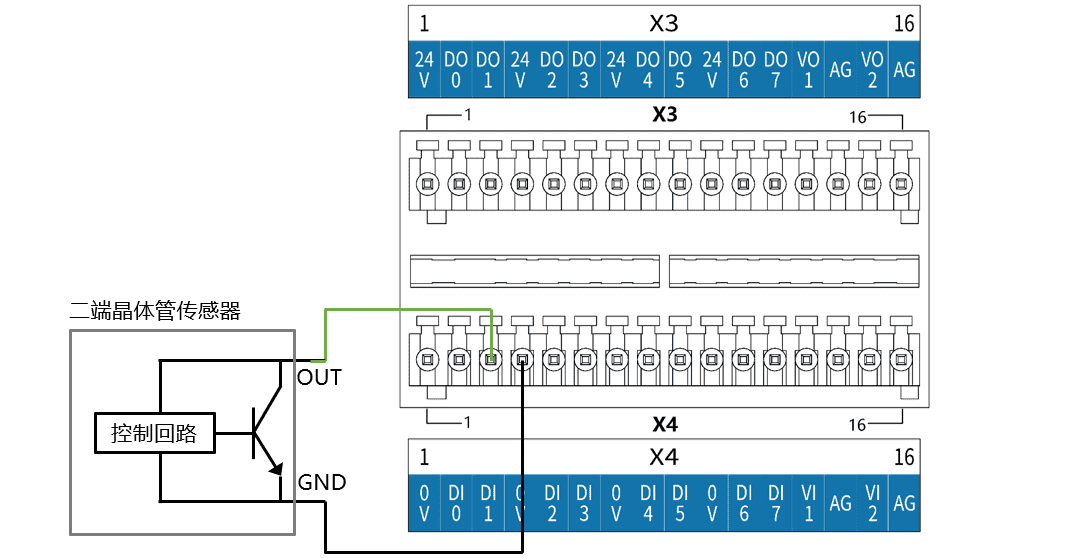
3. Connecting a load to a DO terminal
The wiring method for connecting an external load to the DO interface is shown in the figure below. 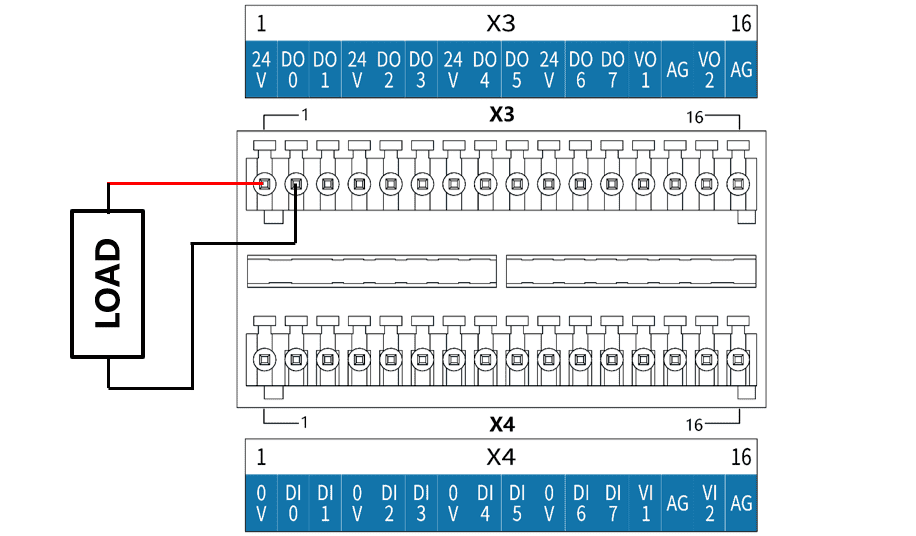
10.5.2 Analog I/O Interfaces
The integrated base panel has 2 analog voltage input interfaces, denoted as VI terminals, and 2 analog voltage output terminals, denoted as VO, as shown in the figure below. 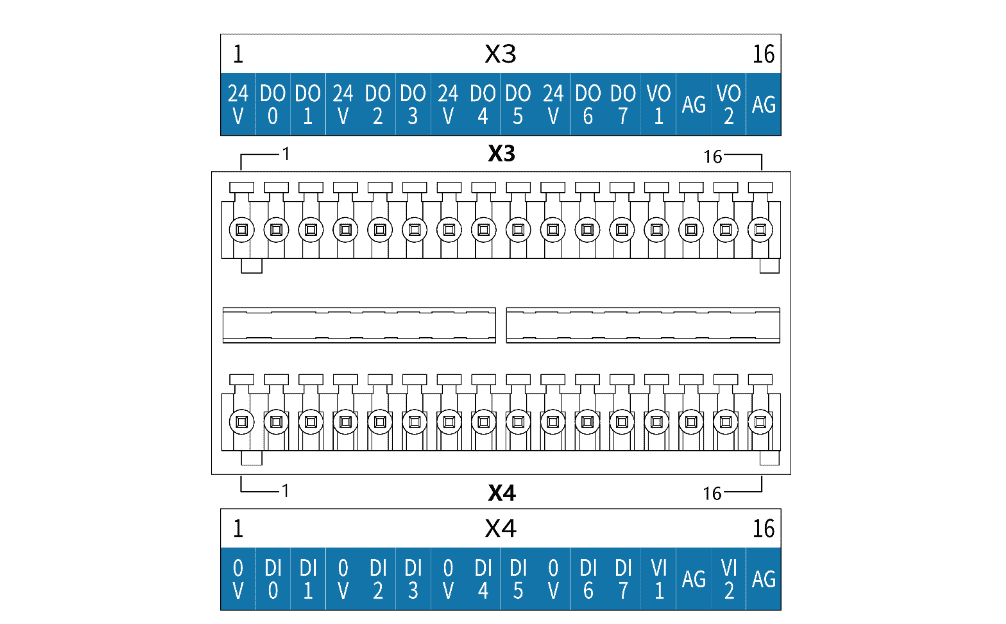
| Input | VI1 | Analog voltage input | VI2 | Analog voltage input |
|---|---|---|---|---|
| Output | VO1 | Analog voltage output | VO2 | Analog voltage output |
| Type | Voltage |
|---|---|
| Input | 0~+10V |
| Output | 0~+10V |
| Accuracy | ±1% |
| Parameter | Minimum | Maximum | Unit |
|---|---|---|---|
| Input voltage | 0 | +10 | V |
| Input resistance | 100K | Ω | |
| VI sampling resolution | 12 | BITS | |
| VI sampling accuracy | 10 | BITS |
| Parameter | Minimum | Maximum |
|---|---|---|
| Output voltage of a single VO terminal | 0V | +10V |
Examples
1. Wiring method for analog voltage input
For analog voltage input, refer to the example of external sensor wiring shown in the figure below. 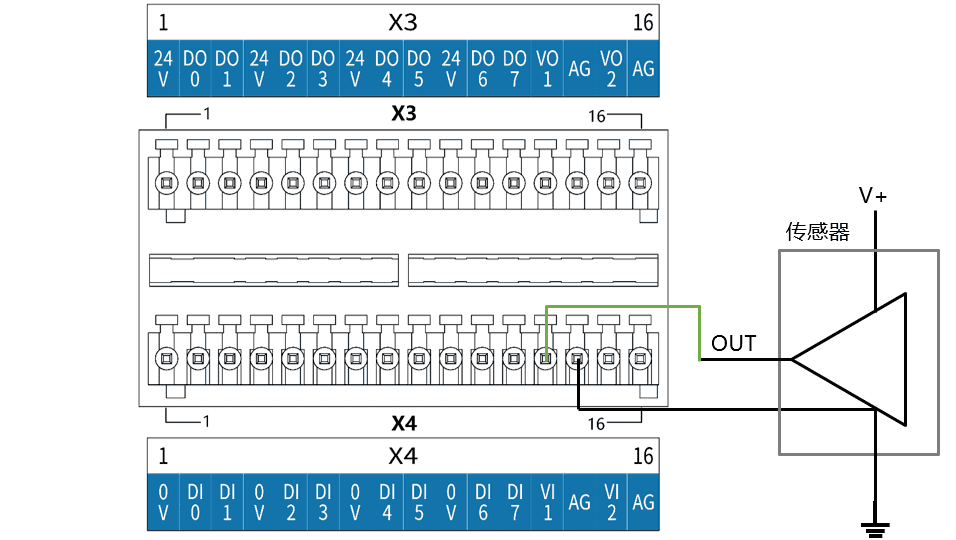
2. Wiring method for analog voltage output
For analog voltage output, refer to the wiring method shown in the figure below. 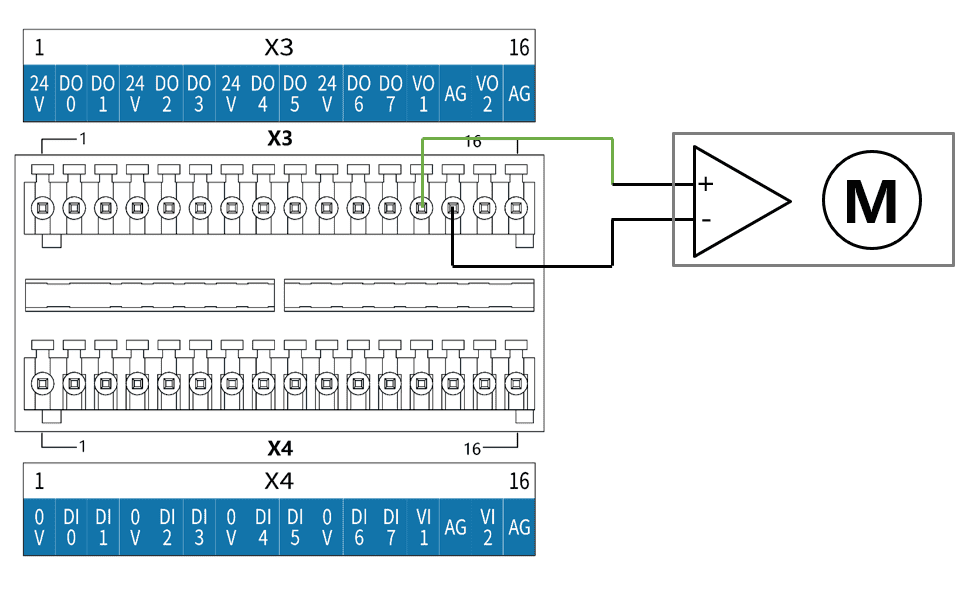
10.5.3 Robot Tool I/O Interfaces
At the wrist of the robot body, the tool end has an 8-pin small connector, which can provide power and control signals for specific tools used at the robot end (such as grippers), with an electrical error of about ±10%. The wire sequence is shown in the figure. 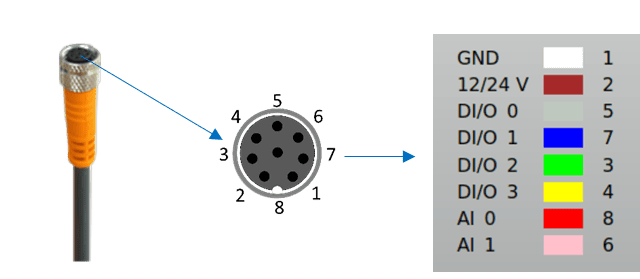
Cable wire sequence function table
The cable is an industrial cable, and the 8 internal wires of different colors represent different functions, as shown in the table below.
| Color | Signal | Pin |
|---|---|---|
| White | GND | 1 |
| Brown | 12/24V | 2 |
| Gray | DI/O0 | 5 |
| Blue | DI/O1 | 7 |
| Green | DI/O2 | 3 |
| Yellow | DI/O3 | 4 |
| Red | AI0 | 8 |
| Pink | AI1 | 6 |
Power supply electrical parameters
In the IO tab of the graphical user interface, set the internal power supply to 0V, 12V, or 24V. The electrical specifications are as follows:
| Parameter | Minimum | Typical | Maximum |
|---|---|---|---|
| Power supply voltage in 24V mode | 23V | 24V | 25V |
| Power supply voltage in 12V mode | 11.5V | 12V | 12.5V |
| Power supply current in both modes | - | 0.8A | 1.0A |
Tool digital output
The digital output is implemented in NPN form. After the digital terminal output is activated, the corresponding connector is driven and connected to GND; after the digital output terminal is disabled, the corresponding connector is in an open circuit. The electrical specifications are as follows:
| Parameter | Minimum | Typical | Maximum | Unit |
|---|---|---|---|---|
| Input voltage | -0.5 | - | Vout+2 | V |
| Logic low voltage | 0 | 1.5 | 2 | V |
| Logic high voltage | Vout-4 | Vout | Vout+2 | V |
| Input resistance | - | 4.3 | - | kΩ |
Tool IO
| Parameter | Minimum | Typical | Maximum | Unit |
|---|---|---|---|---|
| Input voltage in voltage mode | 0 | - | 10 | V |
| Input resolution in the 0V to 10V voltage range | - | 2.5 | - | mV |
Analog terminal electrical parameters
| Parameter | Minimum | Maximum |
|---|---|---|
| Voltage input analog value AI 0 | 0V | +10V |
| Voltage input analog value AI 1 | 0V | +10V |
| Sign | Description |
|---|---|
| When connecting tools and grippers, ensure that interrupting the power supply will not cause any hazard, such as the workpiece falling from the tool. |
11 Control Handle
11.1 Introduction
The control handle enables quick operation of the robot system. The control handle function can be configured to be disabled/enabled in the teaching software, and it is enabled by default at the factory. Magnets are provided on the back of the control handle for easy attachment. Its structure is shown in Figure 11-1 below. 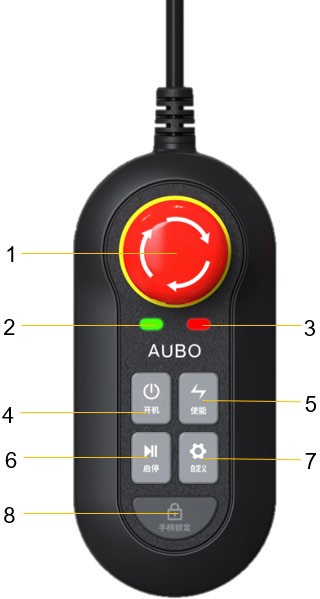
| No. | Name | Function |
|---|---|---|
| 1 | Emergency stop button | Pressing it enables the emergency stop of the robot. To return to normal mode, rotate the button in the direction indicated on the button |
| 2 | Power indicator light | Indicates the robot power on/off status: Off: the robot is not powered on Blinking: the robot is powered on and the robot arm is not powered Steady on: the robot is powered on and the robot arm is powered |
| 3 | Lock indicator light | Indicates the handle lock status: Steady on: the handle is locked and other buttons are invalid Off: the handle is not locked and other buttons are valid |
| 4 | Power on/off button | Powers the robot on or off |
| 5 | Enable button | Controls power-on, power-off, and enabling of the robot arm |
| 6 | Start/stop button | Controls program start/stop of the robot arm, and pause/resume during operation; used for quick operations without the teaching software during work, and for commissioning checks during deployment or maintenance |
| 7 | Custom button | Users can customize the function of this button in the teaching software |
| 8 | Handle lock button | Used to lock and unlock the control handle |
11.2 Operation of the Control Handle
1. Power on:
Long press the power on/off button of the control handle  for 2s and then release it. The buzzer beeps once, and the robot enters the "power-on process". Wait about 20s until the buzzer beeps once again, the power indicator light
 starts blinking, and the controller finishes powering on.
2. Control of the robot arm:
- Powering on the robot arm: When the robot arm is powered off, short press the enable button of the control handle
 . The buzzer beeps once and the robot arm starts powering on. Wait about 20s until the buzzer beeps once again; at this time, the power indicator light changes from blinking to steady on, and the robot arm has finished powering on.
- Enabling the robot arm: When the robot arm is powered on but not enabled, short press the enable button . The robot arm vibrates, the six joints emit clicking sounds in sequence and release the brake system, and the robot enters an operable state.
- Powering off the robot arm: When the robot arm is powered on, long press the enable button for 2s and then release it. The robot arm is disabled and powered off, the power indicator light changes from steady on to blinking, and the buzzer beeps twice to indicate that power-off is complete.
3. Program control:
- When no program is running (just after power-on or after the running program has stopped), long press the start/stop button of the control handle
 for 2s and then release it to start the program. If no default program is set, the robot arm will not perform any action.
- When a program is running, short press the start/stop button to pause/resume the program.
- When a program is running, long press the start/stop button for 2s and then release it to stop the program (it cannot be resumed after stopping; the program can only be restarted).
4. Handle lock/unlock:
- When the handle is not locked, long press the handle lock button
 for 2s and then release it. The buzzer beeps once, the handle lock indicator light
 stays on, the control handle enters the locked state, and all buttons except the emergency stop button are unavailable.
- When the handle is locked, long press the handle lock button for 2s and then release it. The buzzer beeps twice, the handle lock indicator light goes off, the control handle is unlocked, and other buttons become available again.
5. Custom function:
Users can configure the function of the custom button  in the teaching software. For specific functions and operations, please refer to the user manual of the teaching software.
6. Power off:
- Long press the power on/off button of the control handle for 2s and then release it. The power indicator light goes off and the buzzer beeps twice to indicate that power-off is complete.
- Forced power off: In any state, long press the power on/off button for 10s to perform a forced power off. The power indicator light goes off and the buzzer beeps twice to indicate that power-off is complete. Forced power off can only be used to shut down the system in abnormal states.
12 Installation and Use
12.1 Installing the Robot
12.1.1 Important Safety Instructions
| Sign | Description |
|---|---|
| 1. Ensure that the integrated base and cables do not come into contact with liquids. A wet integrated base may cause injury or death. 2. The integrated base shall not be exposed to dust or humidity exceeding the IP20 rating. Pay close attention to environments with conductive dust. |
| Installation environment conditions: 1. No corrosive gases or liquids 2. No oil mist 3. No salt mist 4. No dust or metal powder 5. No mechanical impact or vibration 6. No electromagnetic noise 7. No radioactive materials 8. Low humidity 9. No flammable items 10. Ambient temperature: 0°C ~ 45°C (recommended range; the operating temperature limit is 0°C ~ 50°C, see 13.2 Technical Specifications) 11. Avoid direct sunlight (avoid outdoor use) Floor load-bearing capacity: Install the robot on a solid surface that is sufficient to withstand at least 10 times the full torsional force of the base joint and at least 5 times the weight of the robot arm. Moreover, the surface must not vibrate. Instructions for installing additional devices: If additional components, such as cables, that are not part of the scope provided by AUBO (Beijing) Intelligent Technology Co., Ltd. are integrated into the robot, the user is responsible for ensuring that these components have no impact and will not affect the safety functions. |
| A safety assessment must be carried out after each robot installation, and the instructions in Chapter 2 (Safety) must be strictly observed. |
12.1.2 Installing the Robot
The robot has a 360° installation position and orientation self-adaptation function. The installation method of the robot is determined according to the task to be completed by the robot and the workspace of the robot. Installation methods include base mounting, hoisting, and wall mounting, as shown in Figure 12-1. 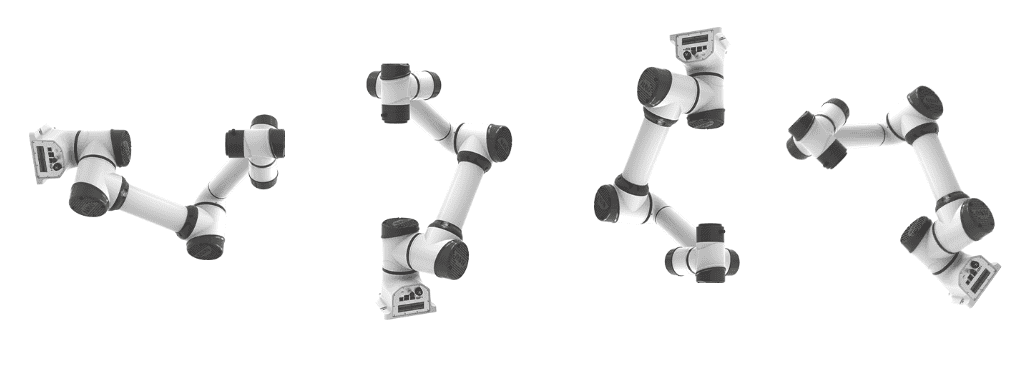
The conventional installation method of the robot is standard mounting. When the installation method of the robot is changed (such as hoisting or wall mounting), the installation angle needs to be reset in the teaching software.
When installing the robot, first locate and drill holes on the installation plane according to the base mounting dimensions of the robot body, and then fix the robot to the plane with 4 M8 bolts. It is recommended to use 2 Ф6mm holes for installing dowel pins to improve installation accuracy. The mechanical dimensions are shown in Figure 12-2. 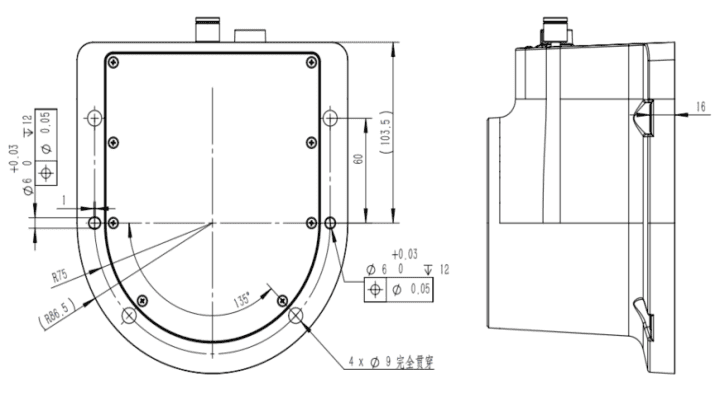
| Sign | Description |
|---|---|
| 1. Ensure that the robot arm is correctly and safely installed in place. 2. If the robot is submerged in water for a certain period of time, it may suffer damage. 3. If the robot is not safely placed on a solid surface, the robot may tip over and cause injury. |
| 1. When mounting on a base, the contact surface between the robot and the base must be in close contact. 2. Users are advised to use a base contact surface with strong heat dissipation performance, such as all-aluminum material. When the working environment exceeds 35°C, it is strongly recommended that users use materials with strong heat dissipation performance. |
12.2 Installing the End Tool
The robot tool flange has 4 M6 threaded holes and 1 Ф6mm positioning hole, which can conveniently connect the fixture to the robot end. The mechanical dimensions of the tool flange are shown in Figure 12-3. 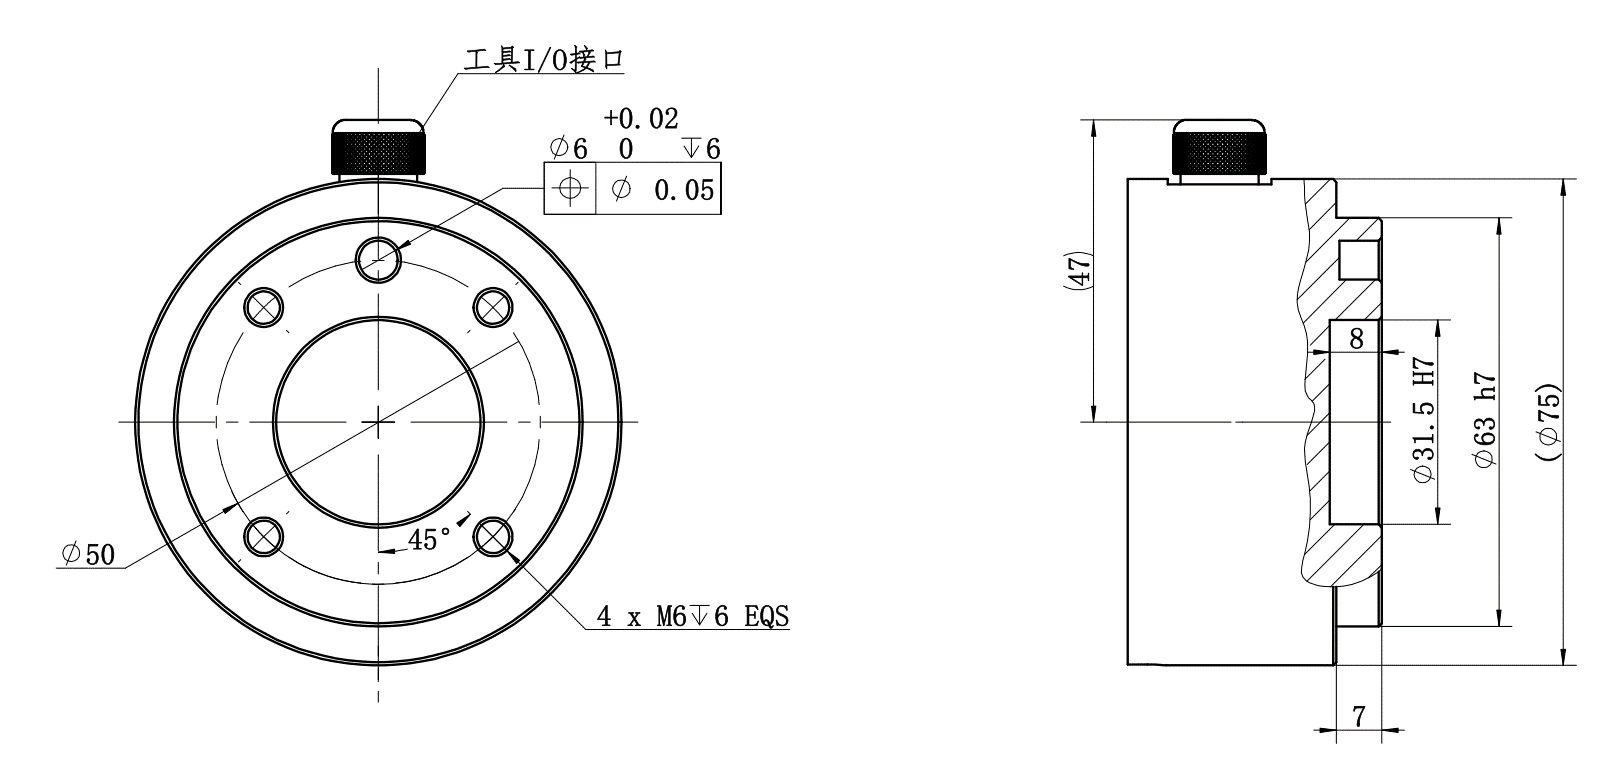
| Sign | Description |
|---|---|
| 1. Ensure that the tool is correctly and safely installed in place. 2. Ensure that the tool is safely structured so that no parts may accidentally fall and cause danger. |
12.3 Cable Connection
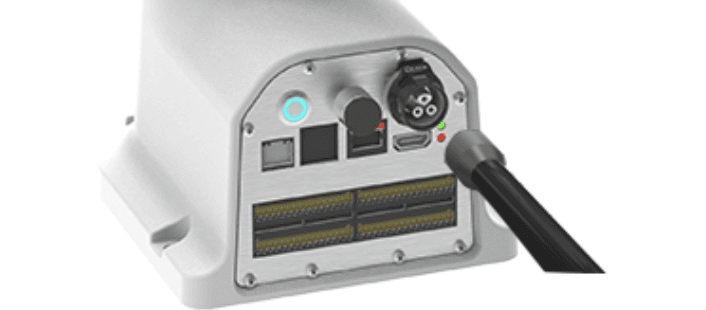
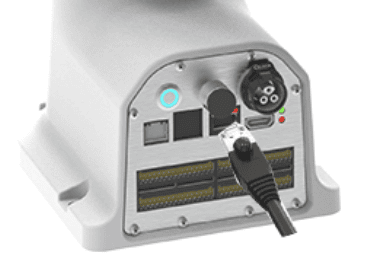
- Insert the plug of the robot cable led out from the 48V power supply end into the socket of the robot base in the direction shown in Figure 12-4.
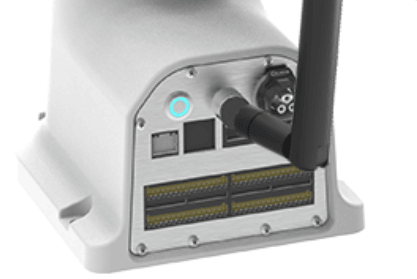
- Insert the wireless antenna into the wireless antenna interface and tighten it, as shown in Figure 12-5.
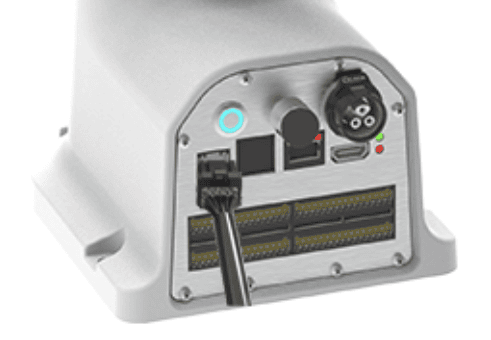
- Connect the control handle cable to the control handle interface of the integrated base as shown in Figure 12-6.
- If wired network communication is required, insert the RJ45 connector of the network cable into the ETHERNET interface of the integrated base.
12.4 Installing the Robot System
The teaching software can only be used after the robot is installed (for specific installation instructions and warning information, please refer to the relevant content of this chapter). The robot system can be installed by referring to the following process. 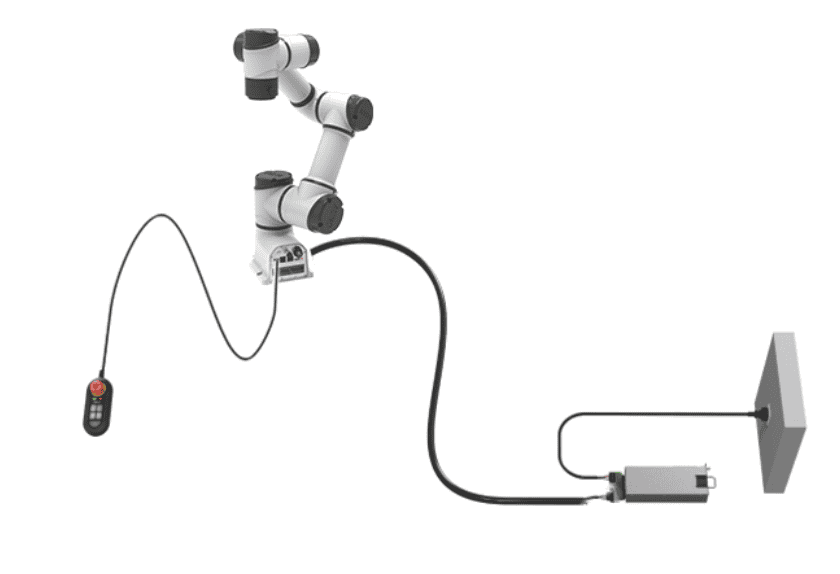
- Unpack and take out the robot, the 48V DC power supply, the control handle, and related cables.
- Install the robot on a shock-proof solid surface.
- Place the 48V power supply and the control handle in appropriate positions.
- Connect the cables to the corresponding robot, control handle, and DC power supply as shown in Figure 12-8 above (for specific connection instructions and warning information, please refer to the preceding content of this chapter).
- Confirm that the safety information for robot installation has been observed and the warning information has been avoided.
- Connect to the external AC power supply.
12.5 Using the Teaching Software
After pressing the power button on the integrated base, wait until the wireless connection indicator light on the integrated base turns yellow and blinks, then the robot can be connected, operated, and controlled through a tablet or computer. For specific operation methods, please refer to the user manual of the teaching software.
13 Appendix
13.1 Revision History
| Version | Date | Revision Content |
|---|---|---|
| v0.0.1 | 2024-06-21 | 1. Released trial version v0.0.1. |
| v0.0.2 | 2026-07-08 | 1. Released trial version v0.0.2. 2. Unified the manual structure, safety instructions, chapter naming, and warning signs. |
| v0.0.3 | 2026-07-08 | 1. Released trial version v0.0.3. 2. Unified the manual structure, safety instructions, chapter naming, and warning signs. |
| v0.0.4 | 2026-09-22 | 1. Released trial version v0.0.4. 2. Added the description of emergency stop categories in [2.7.1 Emergency Stop Device], and added a glossary chapter in the appendix. |
13.2 Technical Specifications
| Robot model | AUBO-ES5 | ||
|---|---|---|---|
| Weight | 24.5 kg | ||
| Payload | 5 kg | ||
| Maximum working radius | 886.5 mm | ||
| Average power | 200W | ||
| Peak power | 600W | ||
| Joint range | Joint1~Joint2, Joint4~Joint6: ±360° Joint3: ±162° | ||
| Joint speed | Joint1~Joint3: 223°/s Joint4~Joint6: 237°/s | ||
| Tool speed | ≤3.4m/s | ||
| Repeatability | ± 0.05 mm | ||
| Degrees of freedom | 6 rotational joints | ||
| External power supply requirement for the robot arm | The rated operating voltage of the robot arm is 48V | ||
| IP rating | IP 54 | ||
| End I/O | Digital input | 4 (configurable) | |
| Digital output | 4 (configurable) | ||
| Analog input | 2 | ||
| End I/O power supply | 0V/12V/24V 0.8A | ||
| Operating temperature | 0-50ºC | ||
| Transportation and storage temperature | -25℃~55℃ | ||
| Humidity | 90% relative humidity (non-condensing) | ||
| Cable length | DC power cable | 3m | |
| AC power cable | 2m | ||
| Power input | DC 48V | ||
| I/O ports | Digital input | 8 (general)/4 (safety) | |
| Digital output | 8 (general)/4 (safety) | ||
| Analog input | 2 | ||
| Analog output | 2 | ||
| RS485 | 1 | ||
| Remote power on/off | 1 | ||
| I/O power supply | DC 24V 2A max | ||
| Cooling method | Passive cooling | ||
| Control handle model | AUBO SMARTSTICK | ||
| Control handle dimensions (L*W*H) | 132mm x 58mm x 45mm (including the thickness of the emergency stop button) | ||
| Control handle cable length | 2m | ||
| Control handle IP rating | IP 54 | ||
13.3 Payload
The allowable payload of the robot wrist varies with the offset of the center of gravity d, where d is the distance from the center of the tool end flange to the center of gravity of the tool. The greater the offset of the center of gravity, the smaller the allowable payload.
| Sign | Description |
|---|---|
| 1. The load conditions shall be within the allowable payload range. 2. The rated payload represents the maximum load capacity and shall not be exceeded under any circumstances. 3. Exceeding the allowable value will cause premature damage to the internal parts of the machine. |
13.4 Glossary
Category 0 stop: Uncontrolled stop, in which the power is cut off immediately, the brakes of each joint are engaged without deceleration control, and the robot may deviate from the programmed path. It is only applicable to extreme situations such as exceeding safety-rated limits or failures in the safety-rated part of the control system. For the definition of stop categories and the requirement to immediately cut off power, please refer to IEC 60204-1:2016 (9.2.2 Stop categories); for the design requirements of the emergency stop function, please refer to EN ISO 13850:2015.
Category 1 stop: Controlled stop with power removed after stopping, in which the robot stops along the programmed path and the power is cut off after the stop is completed, balancing safety and path stability. For the definition of stop categories and the requirement to cut off power after stopping, please refer to IEC 60204-1:2016 (9.2.2 Stop categories); for the design requirements of the emergency stop function, please refer to EN ISO 13850:2015.
Category 2 stop: Controlled stop with power maintained, in which the robot keeps powered after stopping, the safety-rated control system maintains the stop position, and operation can be resumed quickly. For the definition of stop categories and the requirement to continuously maintain power, please refer to IEC 60204-1:2016 (9.2.2 Stop categories). Category 2 stop shall not be used as an emergency stop, so EN ISO 13850:2015 does not apply.
Integrator: The integrator is the organization that designs the final installation of the robot. The integrator is responsible for carrying out the final risk assessment and must ensure that the final installation complies with local laws and regulations.
Risk assessment: Risk assessment is the entire process of identifying all risks and reducing the risks to an appropriate level. Risk assessment shall be documented and archived. For details, please refer to ISO 12100.
Performance level: The performance level (PL) is a discrete level used to describe the ability of each safety-related part of a control system to perform a safety function under predictable conditions. PLd is the second highest reliability classification, which means that the safety function is quite reliable. For more information, please refer to EN ISO 13849-1:2008.